Introdução à Robótica com Three.js
ENEI 2018
Agenda
- Introdução
- Demo 2D
- Three.js
- Perguntas
Dialecto
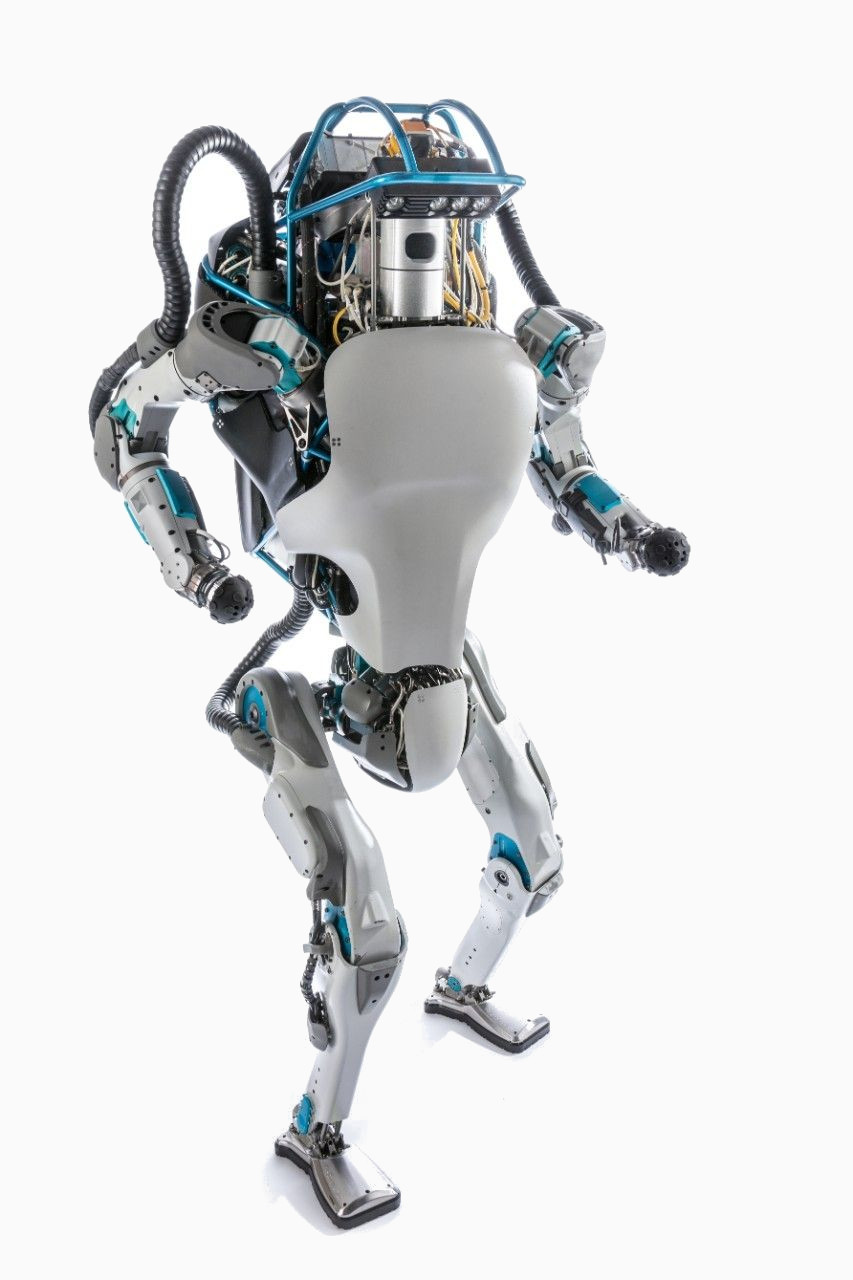 Atlas (Boston Dynamics)
- Joint, link, end-effector
- Base fixa / flutuante
- Fixed / floating base
- Configuração, q
- Configuration, q
- Graus de liberdade
- Degrees of freedom
- Curse of dimensionality
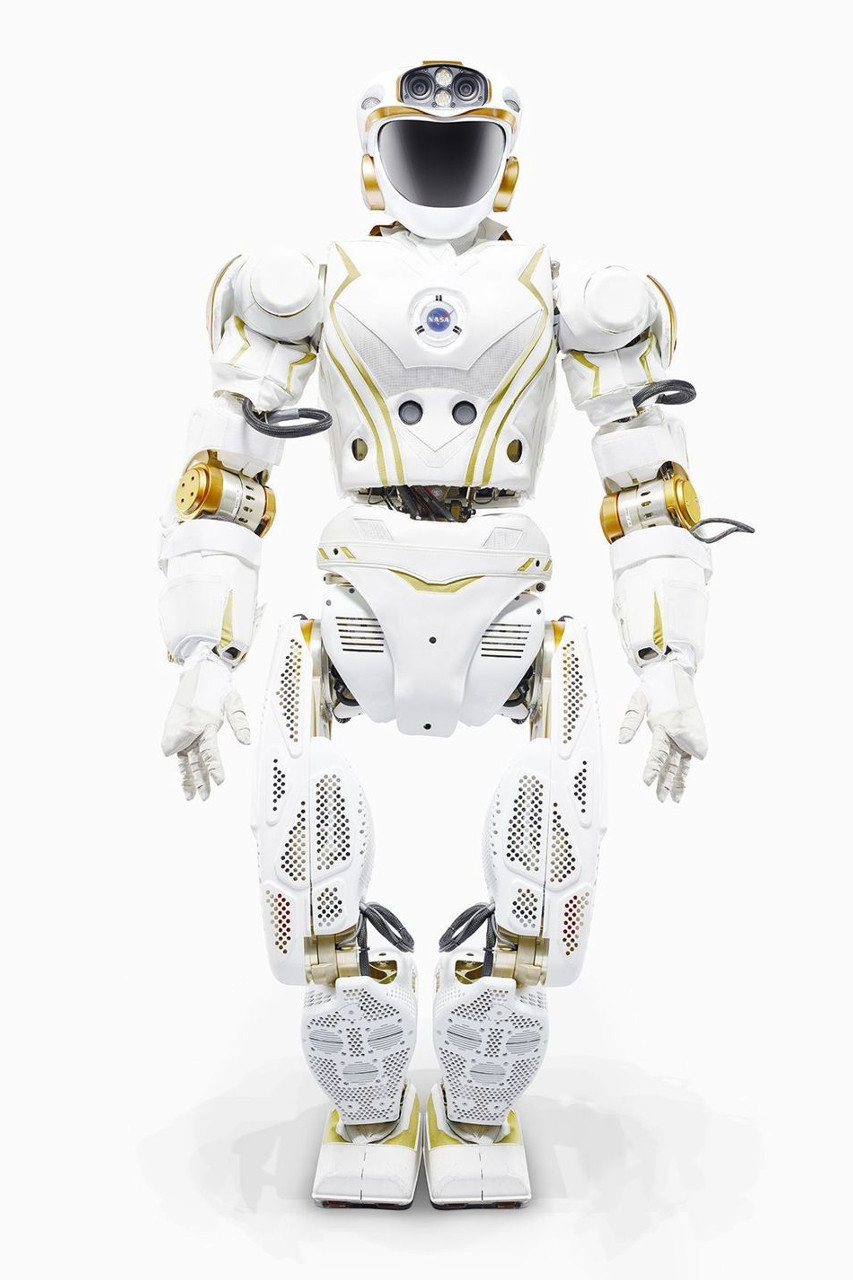 Valkyrie (NASA)
Demo 2D
[Link]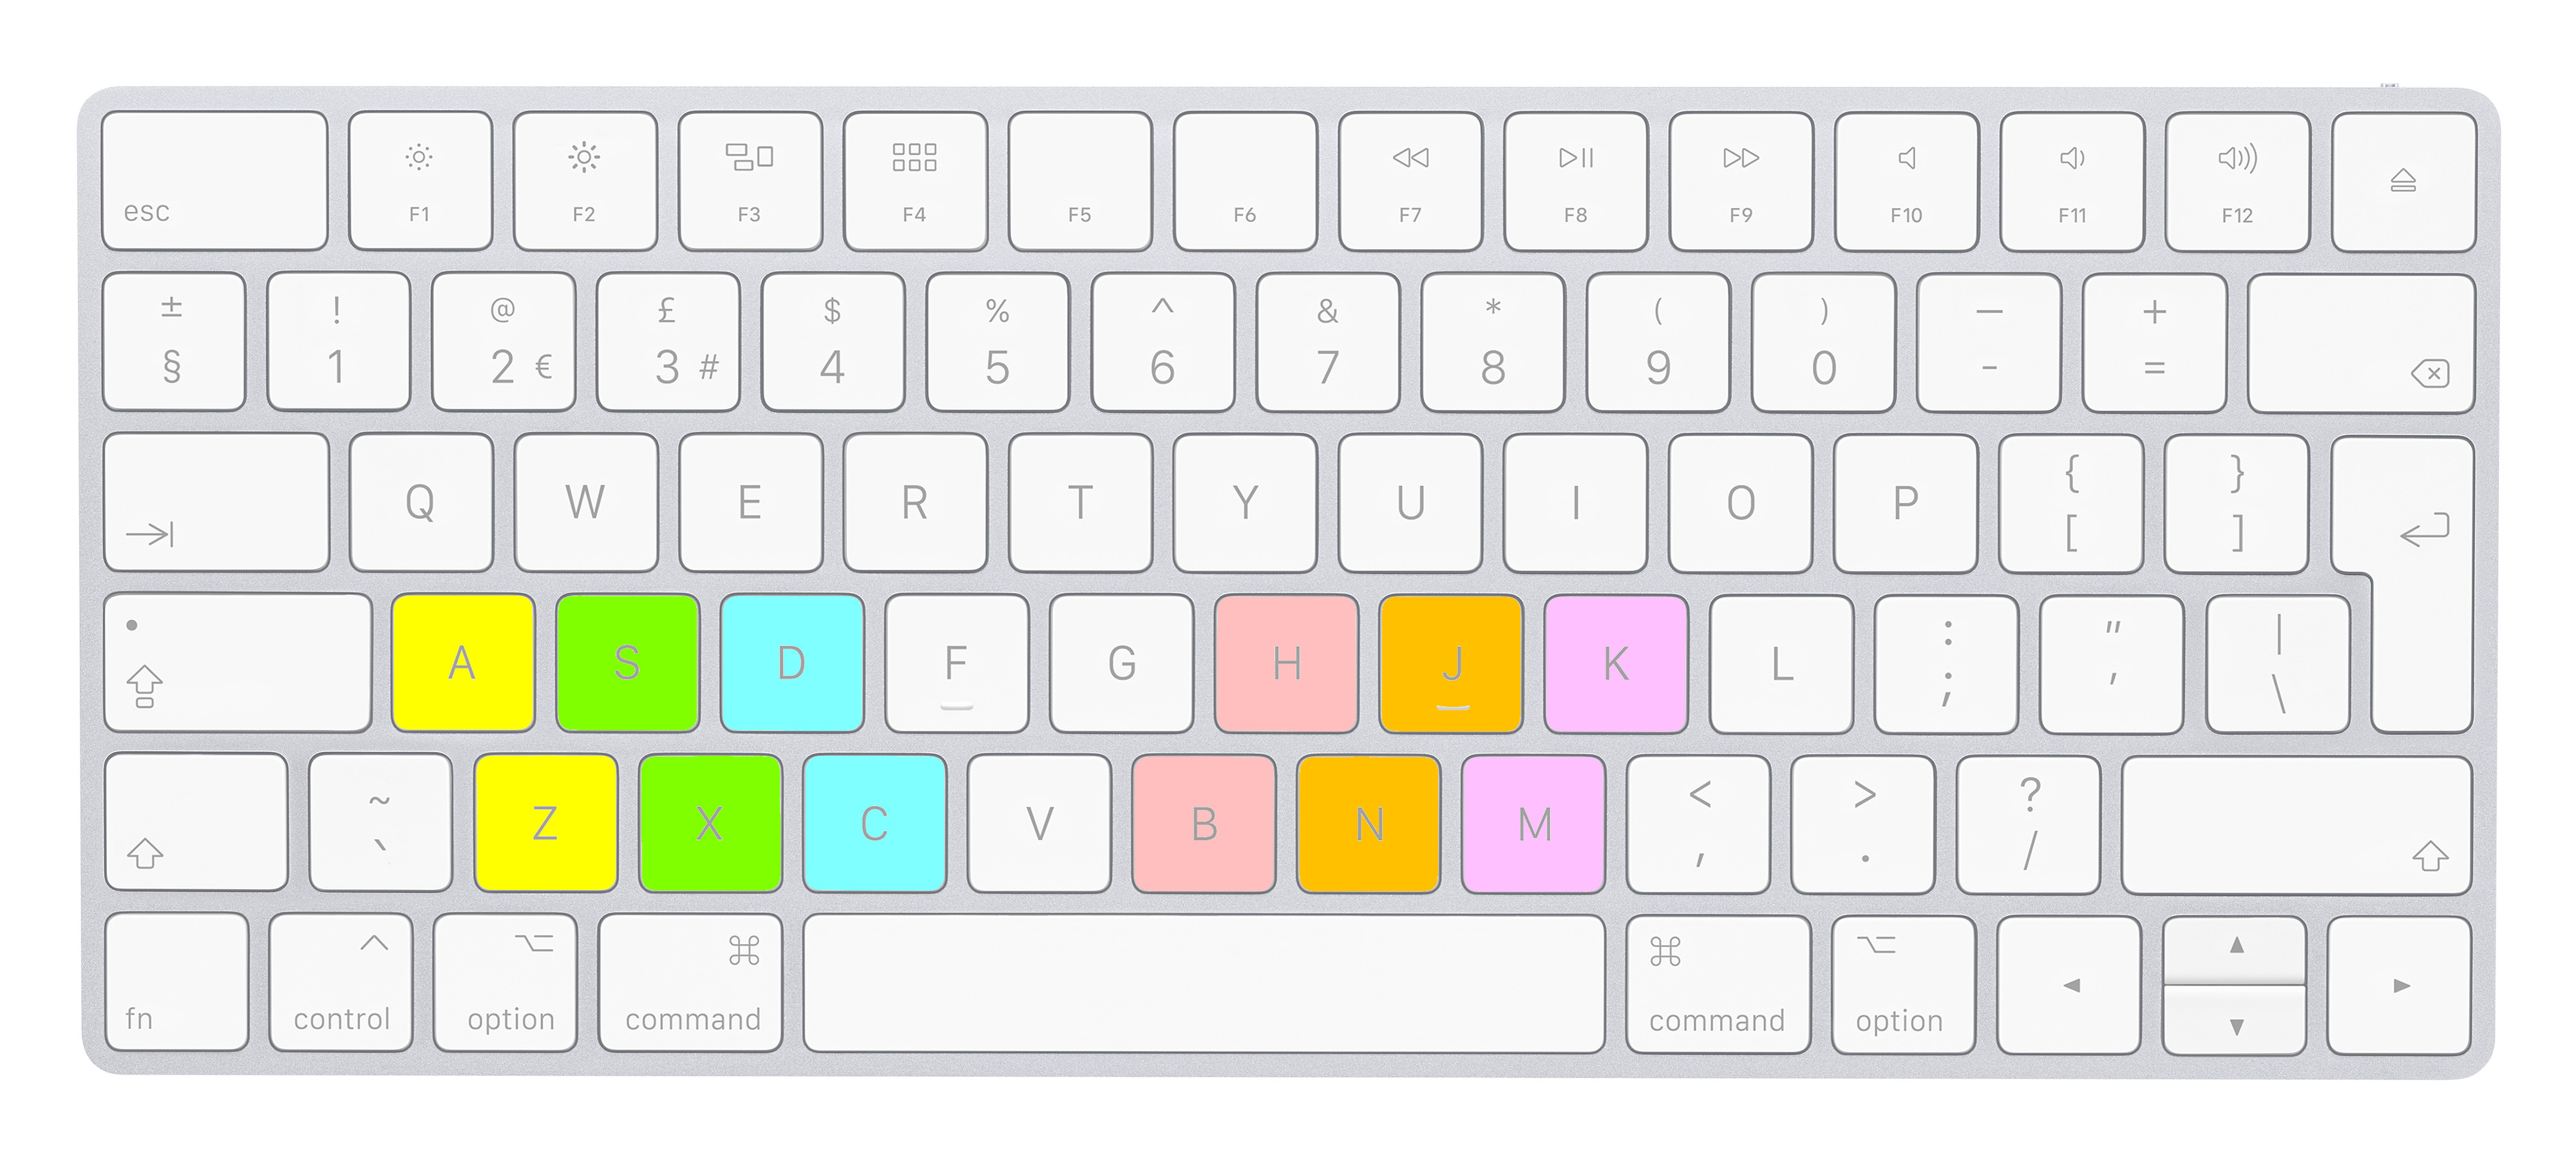
Cada cor controla um grau de liberdade.
Cinemática (Kinematics)
"É o ramo da física que se ocupa da descrição dos movimentos dos corpos, sem se preocupar com a análise das forças em causa (dinâmica)".
Directa
Forward Kinematics, FK
Dada uma configuração q,
onde está o end-effector?
Forward Kinematics, FK
Dada uma configuração q,
onde está o end-effector?
Inversa
Inverse Kinematics, IK
Dada uma pose, quais são
as configurações possíveis?
Inverse Kinematics, IK
Dada uma pose, quais são
as configurações possíveis?
Animação Digital
De que forma se relaciona com robótica?Phase-Functioned Neural Networks for Character Control
Bio IK for Generic Inverse Kinematics in Unity3D
Three.js
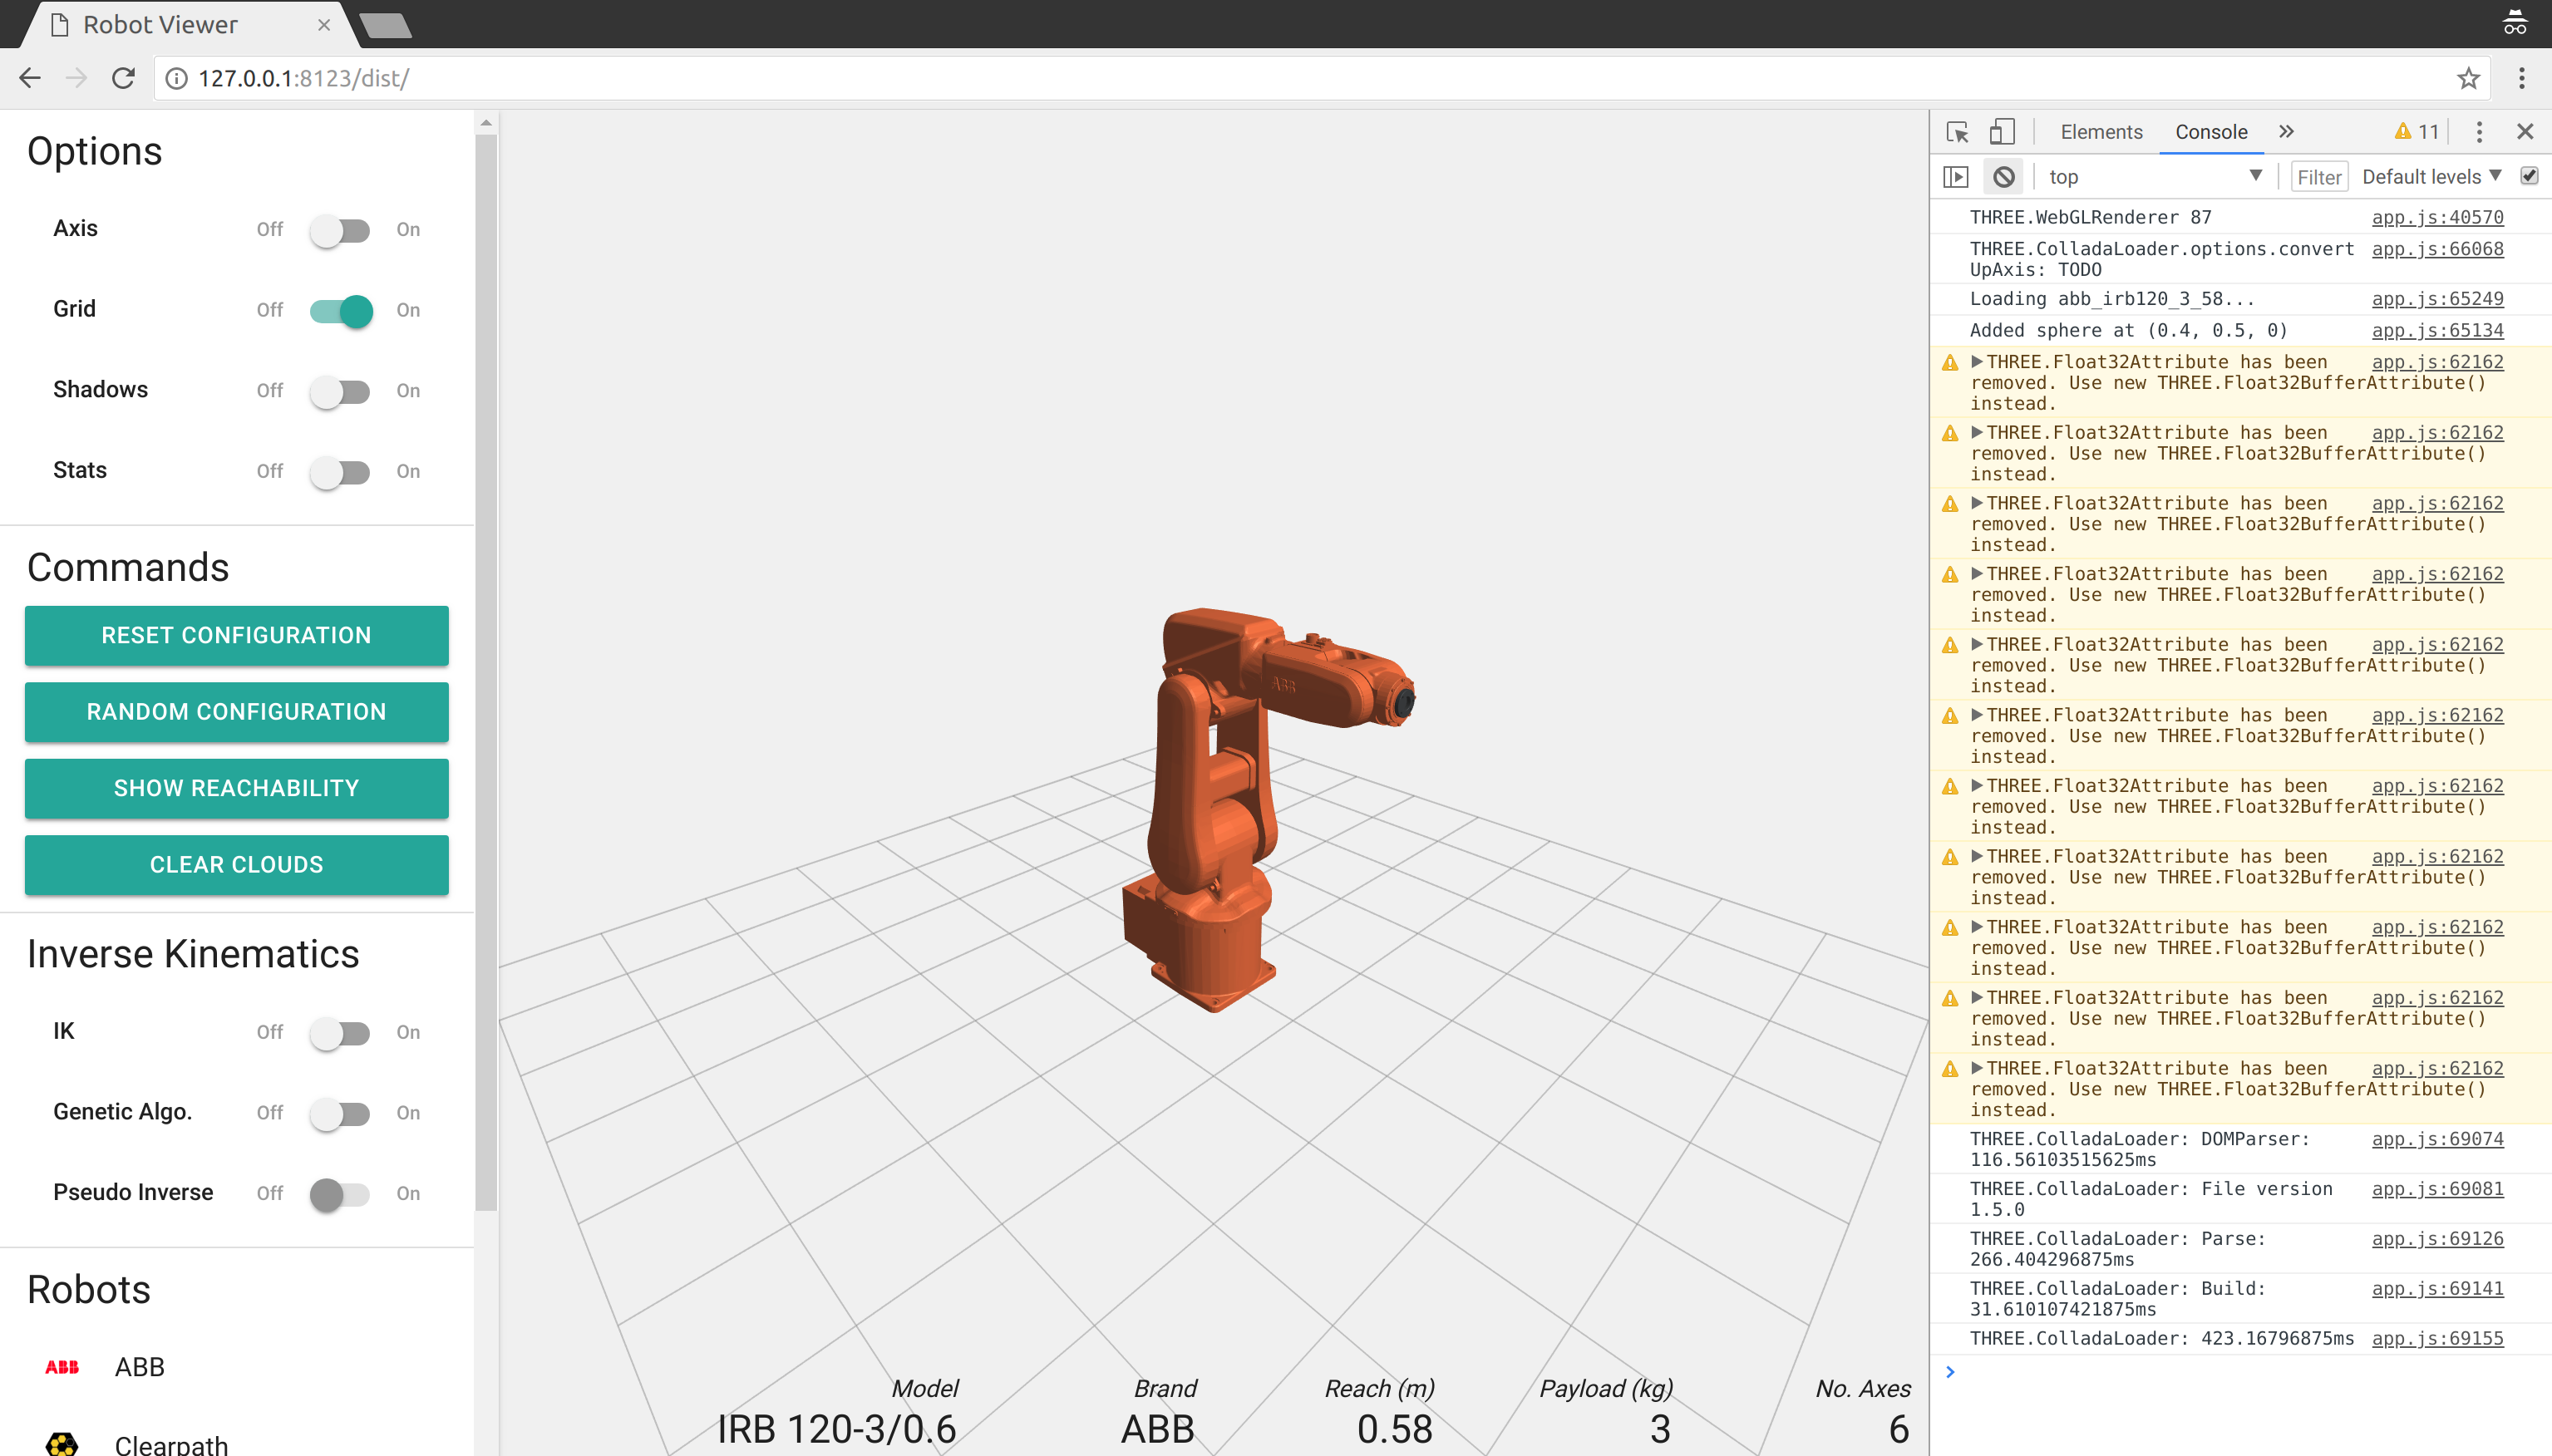
Three.js
// #enei2018 ...
// Reset configuration
$('#reset-button').click(function () {
    // #enei2018 ...
})

// Random configuration
$('#random-button').click(function () {
    // #enei2018 ...
})
src/app.js — 7 ocurrências
src/js/Robot.js — 4 ocurrências
src/js/Robot.js — 4 ocurrências
Sugestões de implementação
src/js/Robot.js
Three.js
get configuration () {
    // #enei2018 ...
}
get zeroConfiguration () {
    // #enei2018 ...
}
if (this._kinematics.joints.hasOwnProperty(prop)) {
    const joint = this._kinematics.joints[prop]
    if (!joint.static) {
        // #enei2018 ...
    }
}
// set configuration (q) { ... }


// #enei2018 ...
Three.js
get configuration () {
    return this._q.slice()
}
get zeroConfiguration () {
 return new Array(this.degreesOfFreedom + 1).join('0').split('').map(parseFloat)
}
if (this._kinematics.joints.hasOwnProperty(prop)) {
    const joint = this._kinematics.joints[prop]
    if (!joint.static) {
        q.push(THREE.Math.randFloat(joint.limits.min, joint.limits.max))
    }
}
// set configuration (q) { ... }
this._q = q.slice()
q = q.slice()
for (const prop in this._kinematics.joints) {
    if (this._kinematics.joints.hasOwnProperty(prop)) {
        if (!this._kinematics.joints[prop].static) {
            this.setJointValue(prop, q.shift())
        }
    }
}
src/app.js
Three.js
// Reset configuration
$('#reset-button').click(function () {
    // #enei2018 ...
})

// Random configuration
$('#random-button').click(function () {
    // #enei2018 ...
})
for (let i = 0; i < 1e4; i++) {


    // #enei2018 ...


}
Three.js
// Reset configuration
$('#reset-button').click(function () {
    robot.configuration = robot.zeroConfiguration
})

// Random configuration
$('#random-button').click(function () {
    robot.configuration = robot.randomConfiguration
})
for (let i = 0; i < 1e4; i++) {
    robot.configuration = robot.randomConfiguration

    for (let j = 0; j < robot.tipLinks.length; j++) {
        const point = new THREE.Vector3()
        point.setFromMatrixPosition(robot.getLinkPose(robot.tipLinks[j]))
        rawPoints[j].push(point)
    }
}
Three.js
case 72: // H
    console.log(`Moving robot to 'home' position`)
    // #enei2018 ...
    break
case 80: // P
    console.log('Executing motion...')
    // #enei2018 ...
    break
// Initialises data structures for tween.js


// #enei2018 ...
kinematicsTween.onUpdate(function () {
    // Update robot configuration, joint by joint.
    // #enei2018 ...
})
Three.js
case 72: // H
    console.log(`Moving robot to 'home' position`)
    moveFromTo(robot.configuration, robot.zeroConfiguration)
    break
case 80: // P
    console.log('Executing motion...')
    moveFromTo(robot.configuration, robot.randomConfiguration)
    break
// Initialises data structures for tween.js
for (const joint of robot._joints) {
    tweenStart[joint] = q_s.shift()
    tweenFinal[joint] = q_t.shift()
}
kinematicsTween.onUpdate(function () {
    // Update robot configuration, joint by joint.
    for (const j of robot._joints) { robot.setJointValue(j, this[j]) }
})