Featured
Rotary Inverted Pendulum
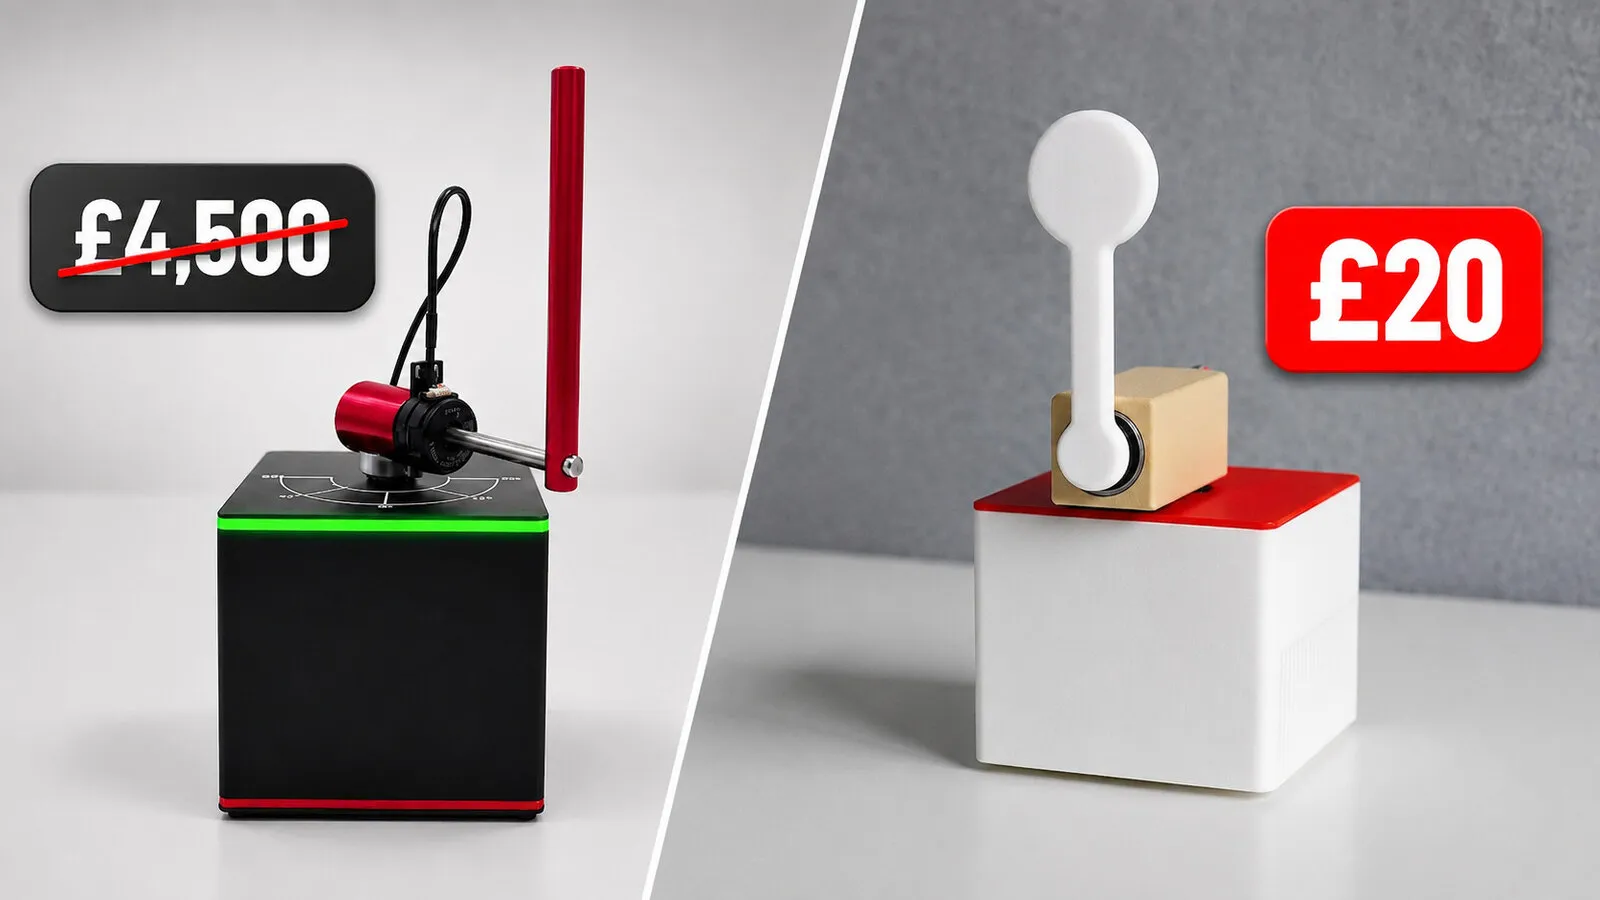
A £20 open-source Furuta pendulum that balances itself with a 689-parameter neural network running standalone on an Arduino Nano.

Henrique Ferrolho
Robotics Technical Lead at ALL3 · PhD
I work on motion planning, trajectory optimisation, and whole-body control for legged robots and manipulators. Outside work I build open-source hardware and interactive simulations, and explain them on YouTube.
drag the pendulum to push it
1.4k
GitHub stars across projects
740k+
views on YouTube
7
peer-reviewed papers
13
years of side projects, since 2013
01Selected work
A £20 open-source Furuta pendulum that balances itself with a 689-parameter neural network running standalone on an Arduino Nano.
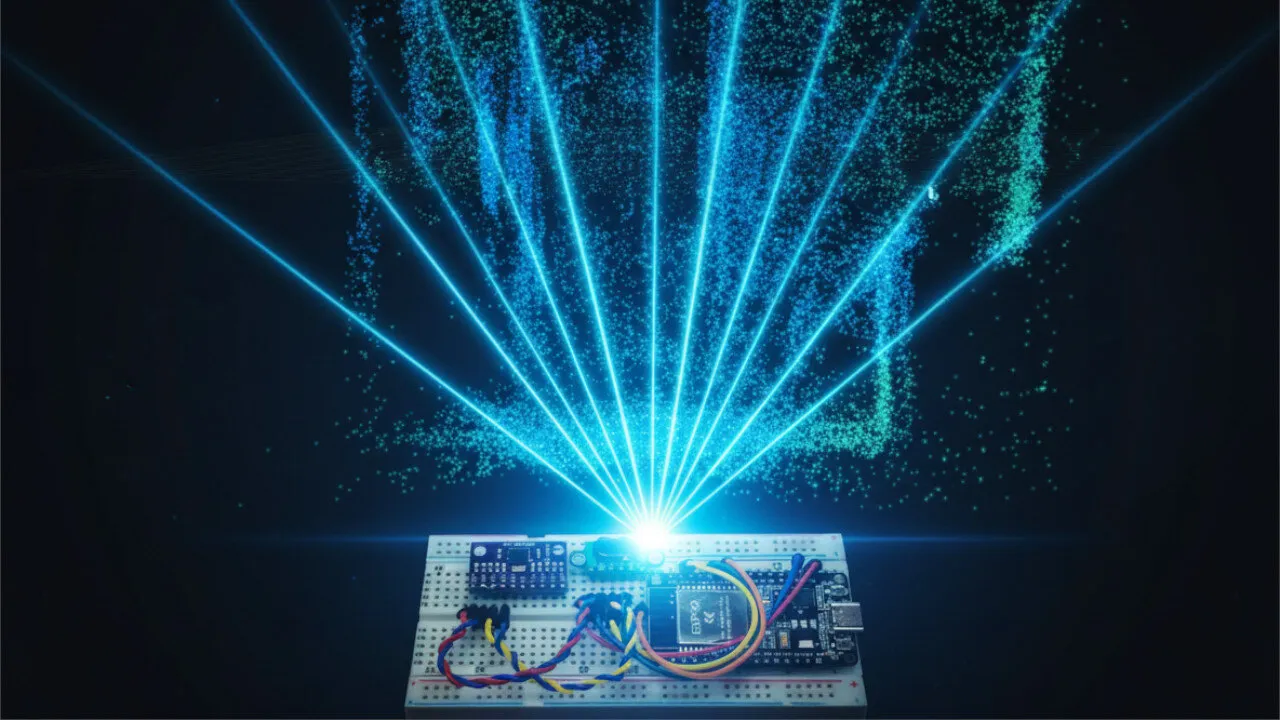
Turn a £5 VL53L5CX multi-zone ToF sensor and an IMU into a real-time 3D point-cloud viewer and room mapper.
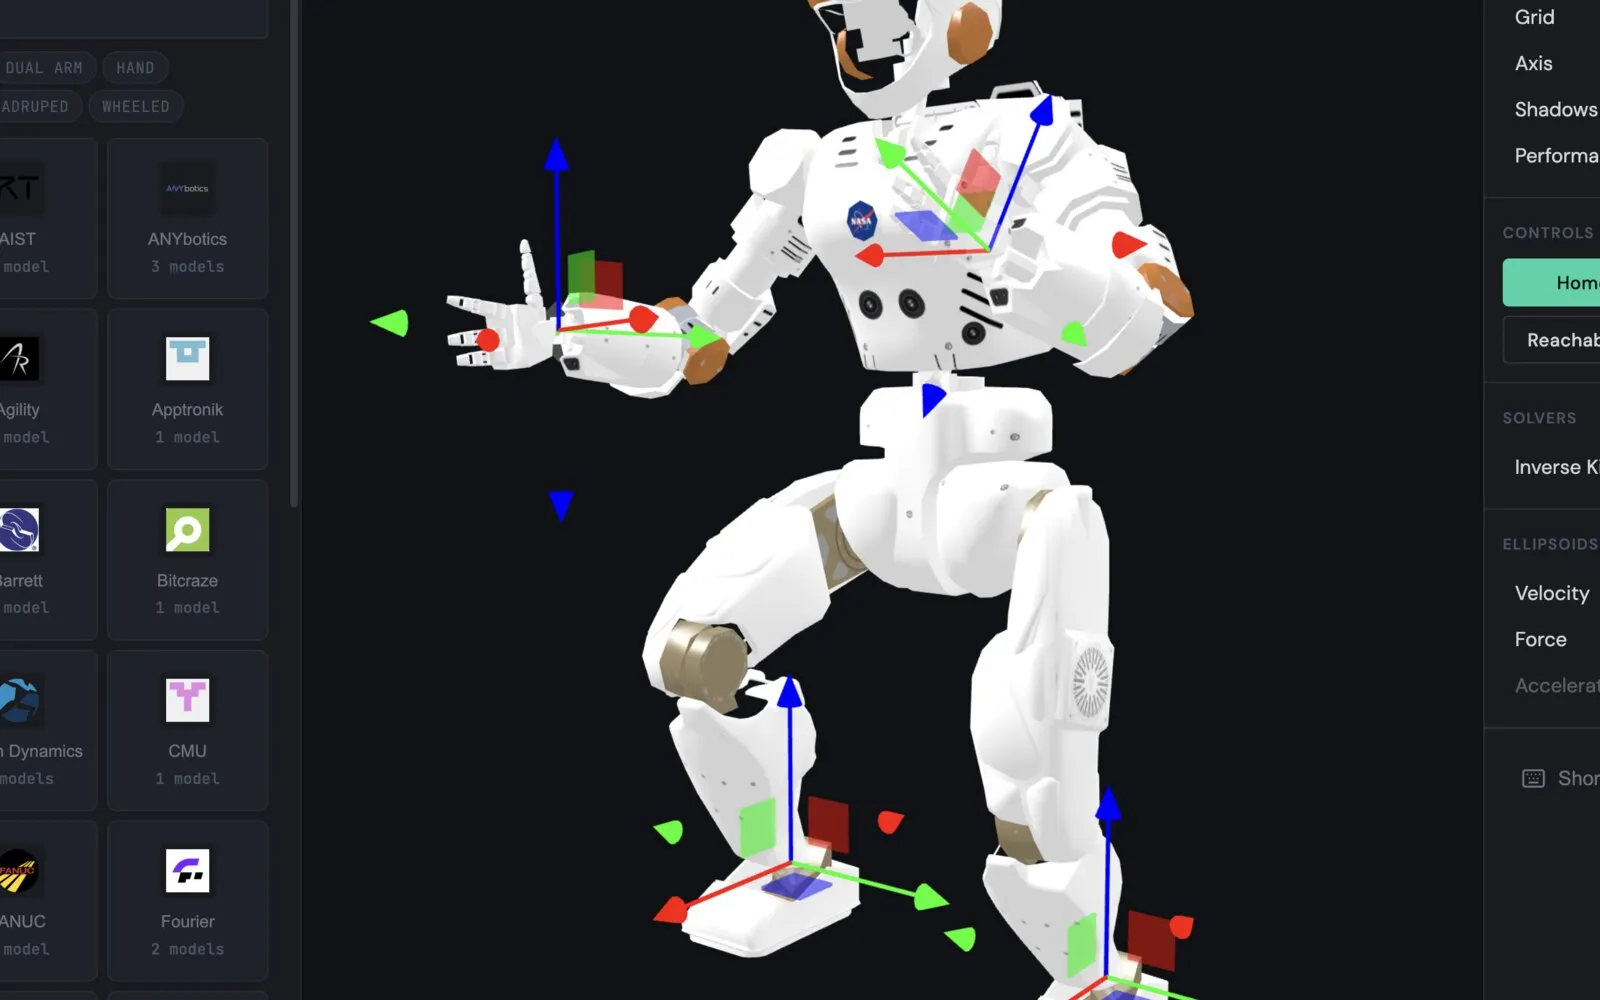
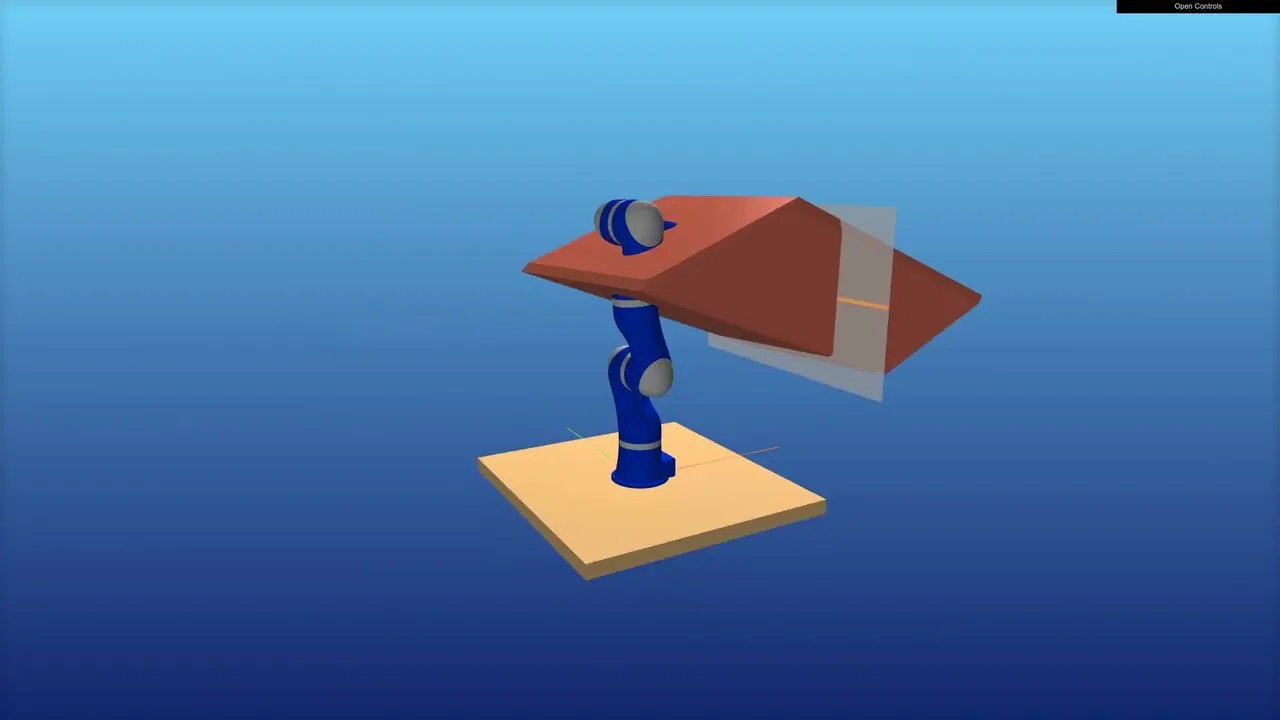
Browse 81+ robots from 35+ brands in the browser, with real-time inverse kinematics, manipulability ellipsoids, and force polytopes.
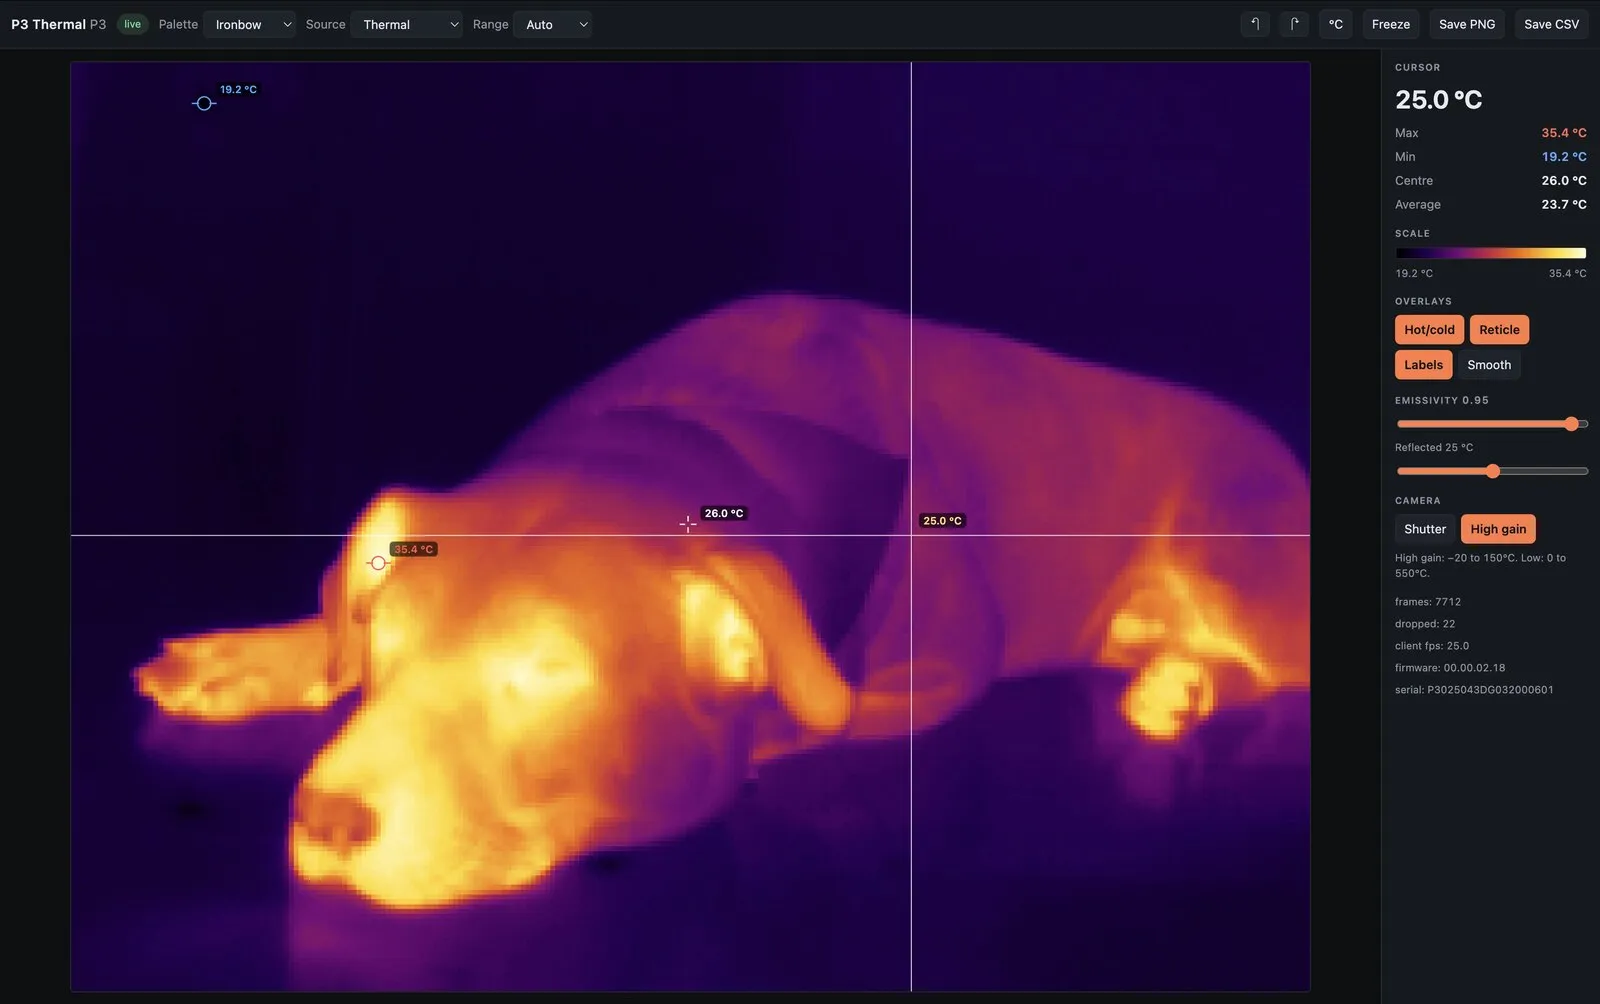
A browser-based viewer for Thermal Master P3/P1 USB thermal cameras. Plug in, open the page, no install — driven directly over WebUSB.
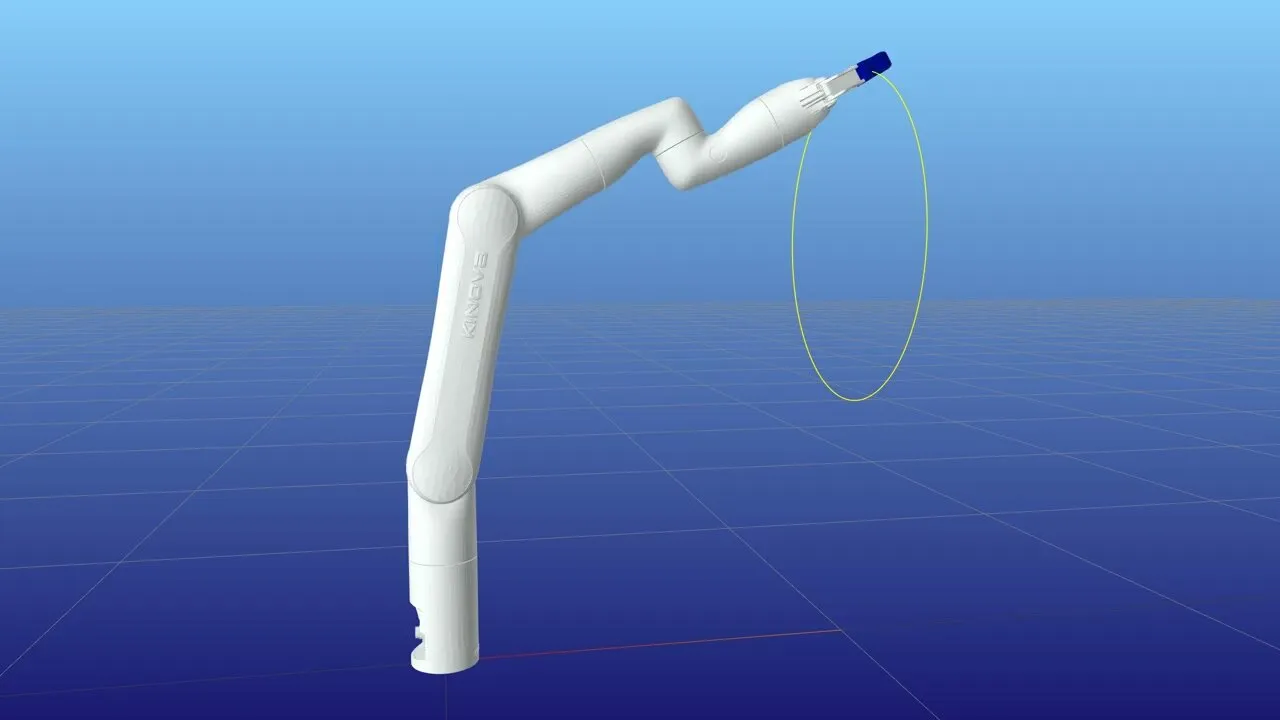
Trajectory Optimisation for Robot Arms — describe a task at a high level and get a full, dynamically consistent trajectory back.
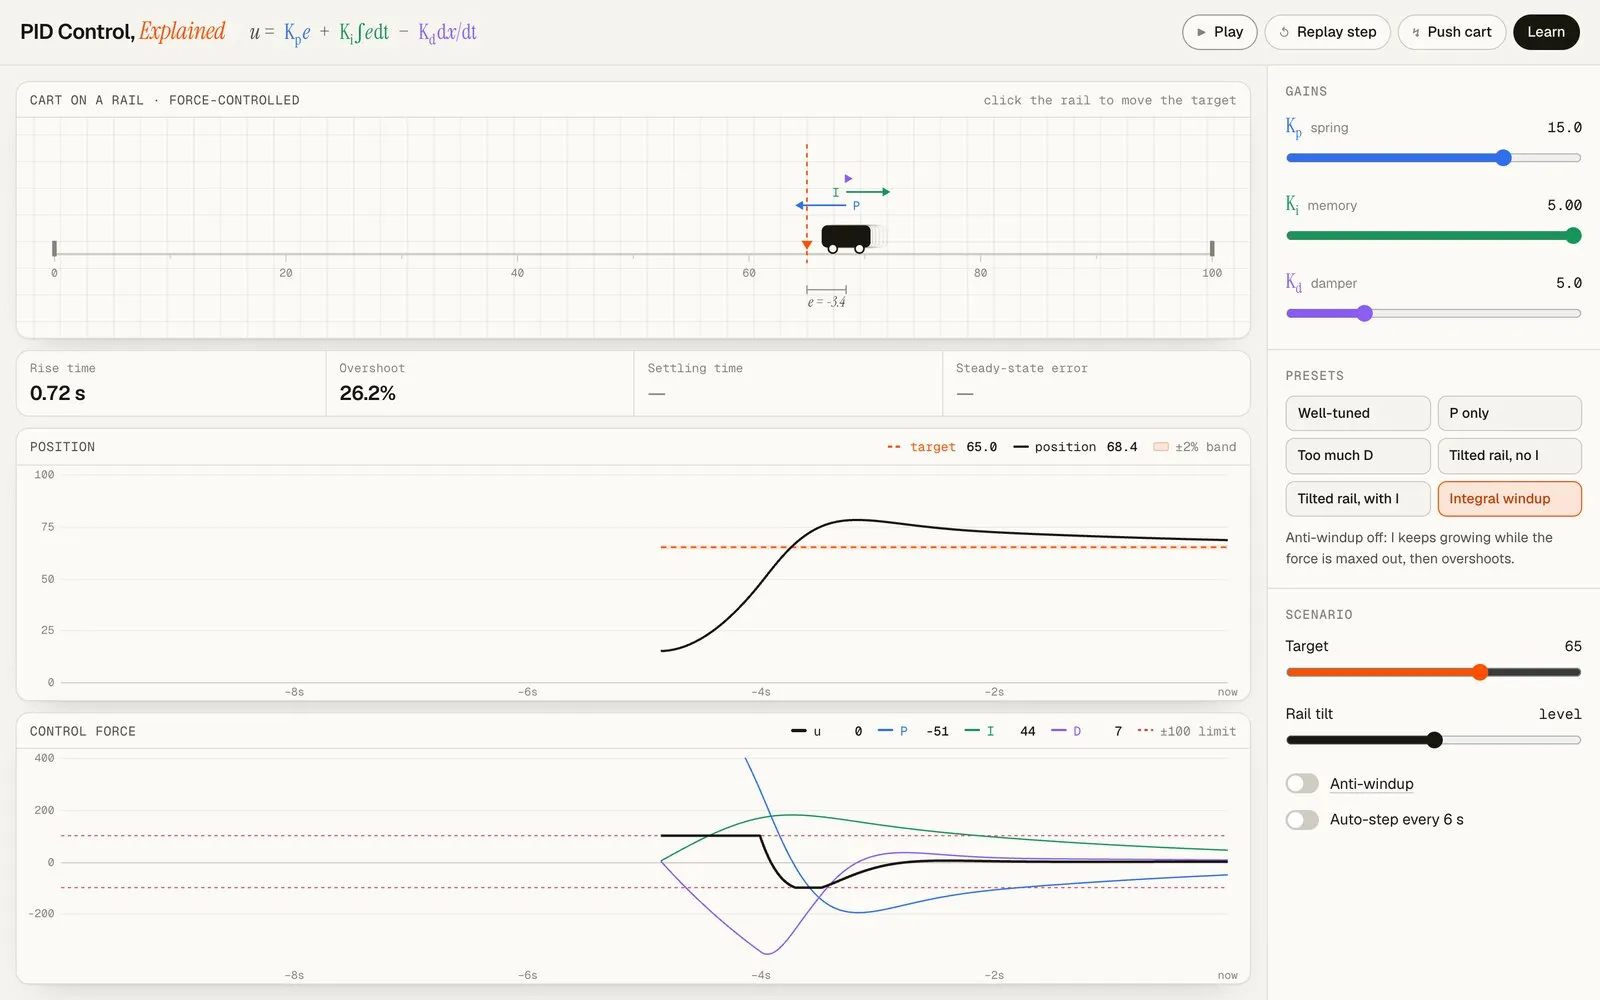
Learn what P, I, and D actually do by tuning a controller on a simulated cart, with live plots and performance metrics.
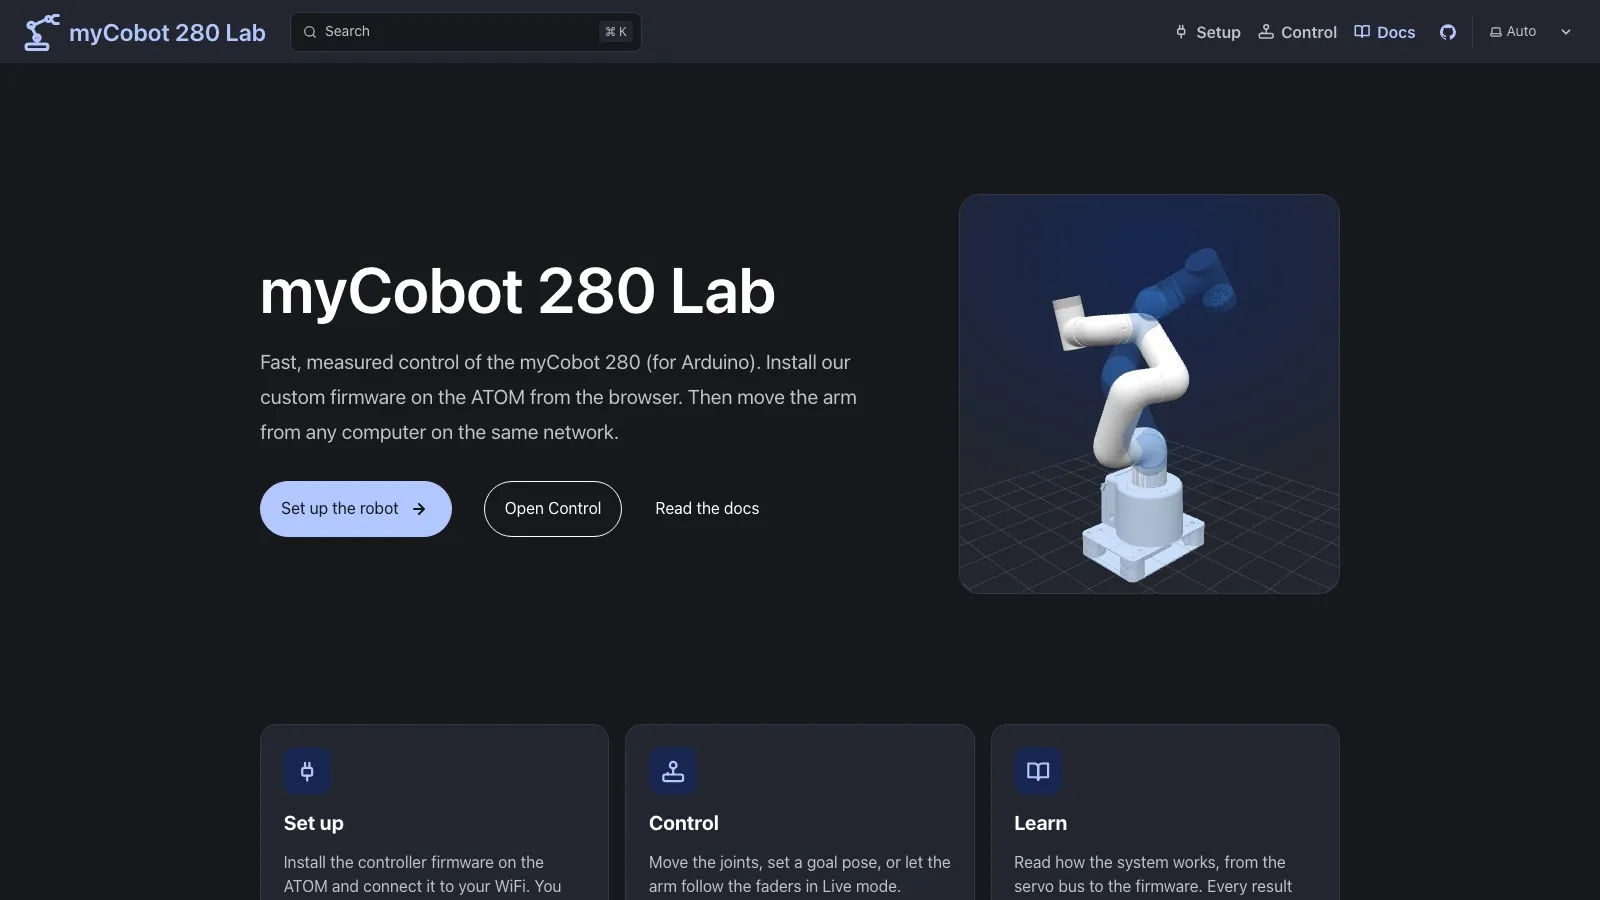
Custom firmware and a browser control page for the myCobot 280 arm — a 500 Hz loop on the arm's own controller, measured from the servo bus up.
02Research
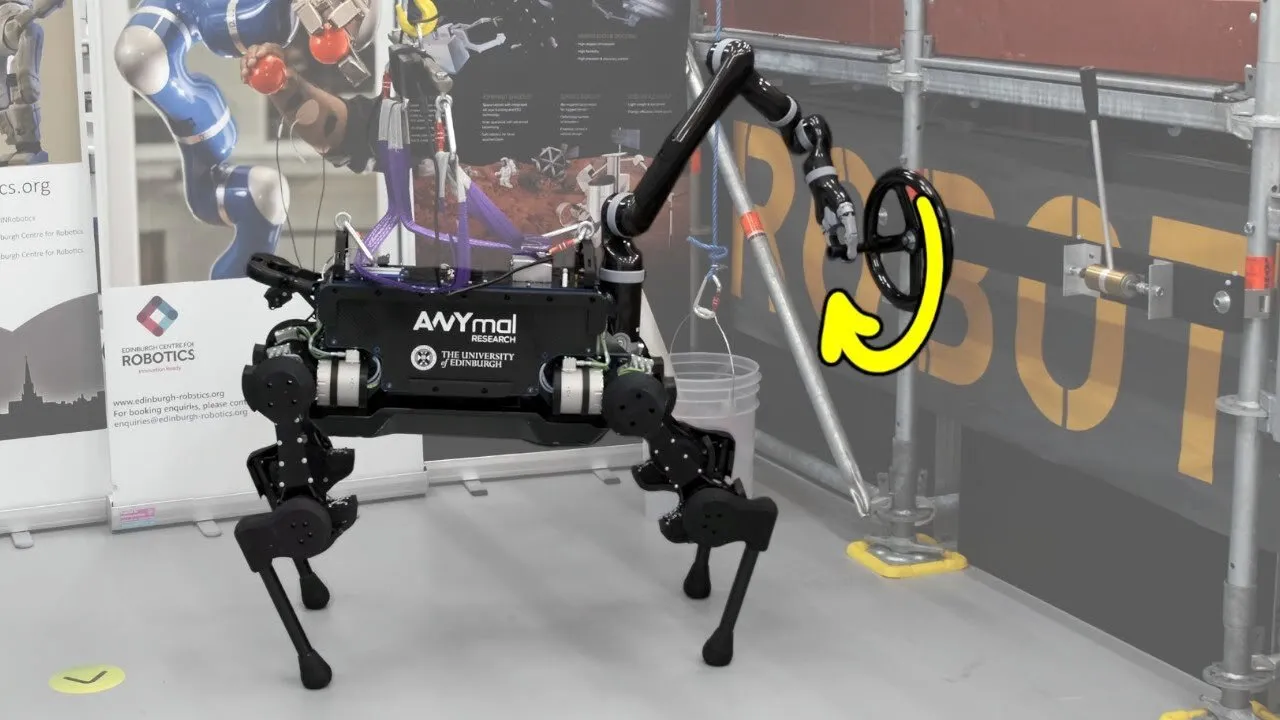
My PhD at the University of Edinburgh asked how to plan dynamic motions that stay feasible when the world pushes back — making robustness to disturbances part of the optimisation itself, not an afterthought for the controller.
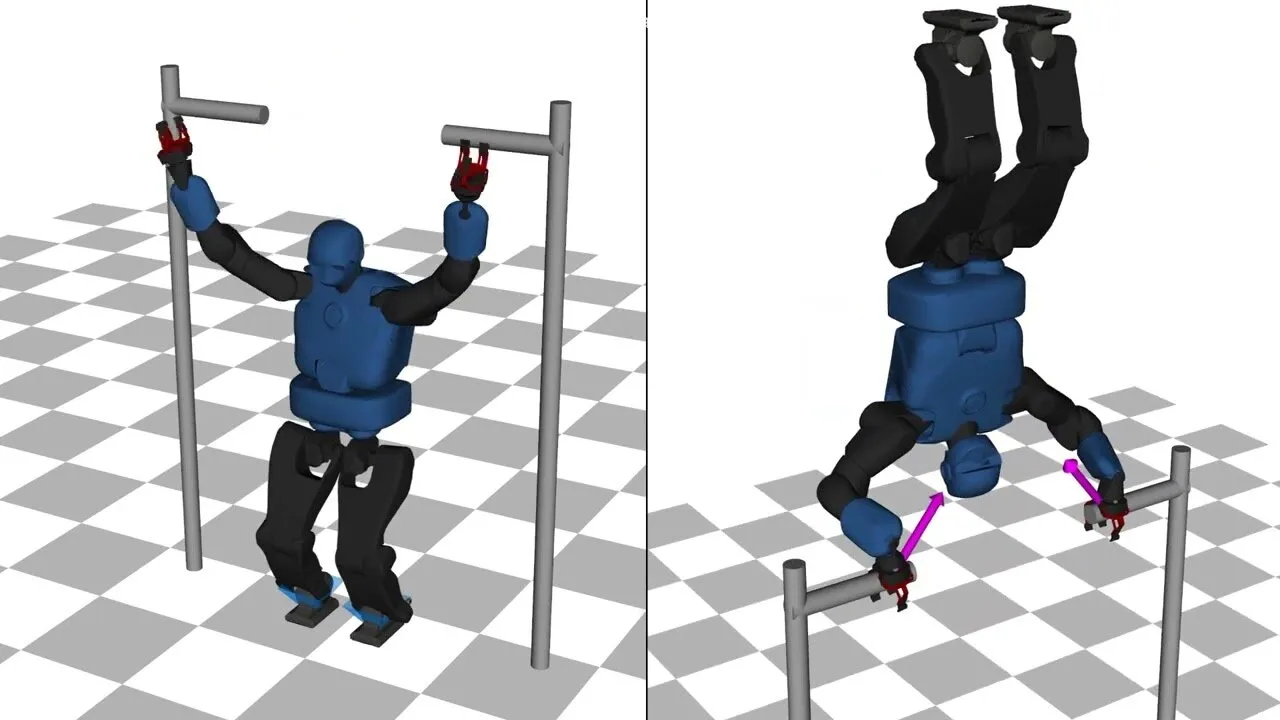
Direct transcription · rigid-body dynamics · force polytopes · legged loco-manipulation on ANYmal, Valkyrie, and TALOS.
JournalAuRo 2023
JournalAuRo 2022
03Log
Seminar on trajectory optimisation with whole-body dynamics for Georgia Tech’s AI4OPT PhD course.
Invited talk at the Beijing Institute for General Artificial Intelligence (BIGAI).
Co-organised “Tactile Sensing for General Purpose Robot Learning” at RSS 2024 in Delft.
RoLoMa — robust loco-manipulation for quadrupeds with arms — published in Autonomous Robots.
Talk at JuliaCon 2023, MIT: using Julia to optimise trajectories for robots with legs.
Defended my PhD, “Trajectory Optimisation for Legged Robots”, at Edinburgh — with no corrections.