ModernRoboticsBook.jl
A Julia port of the Modern Robotics textbook library — rigid-body motions, kinematics, dynamics, trajectory generation, and control.
- Year
- 2019 – 2026
- Topics
- Robotics, Education
- Stack
- Julia
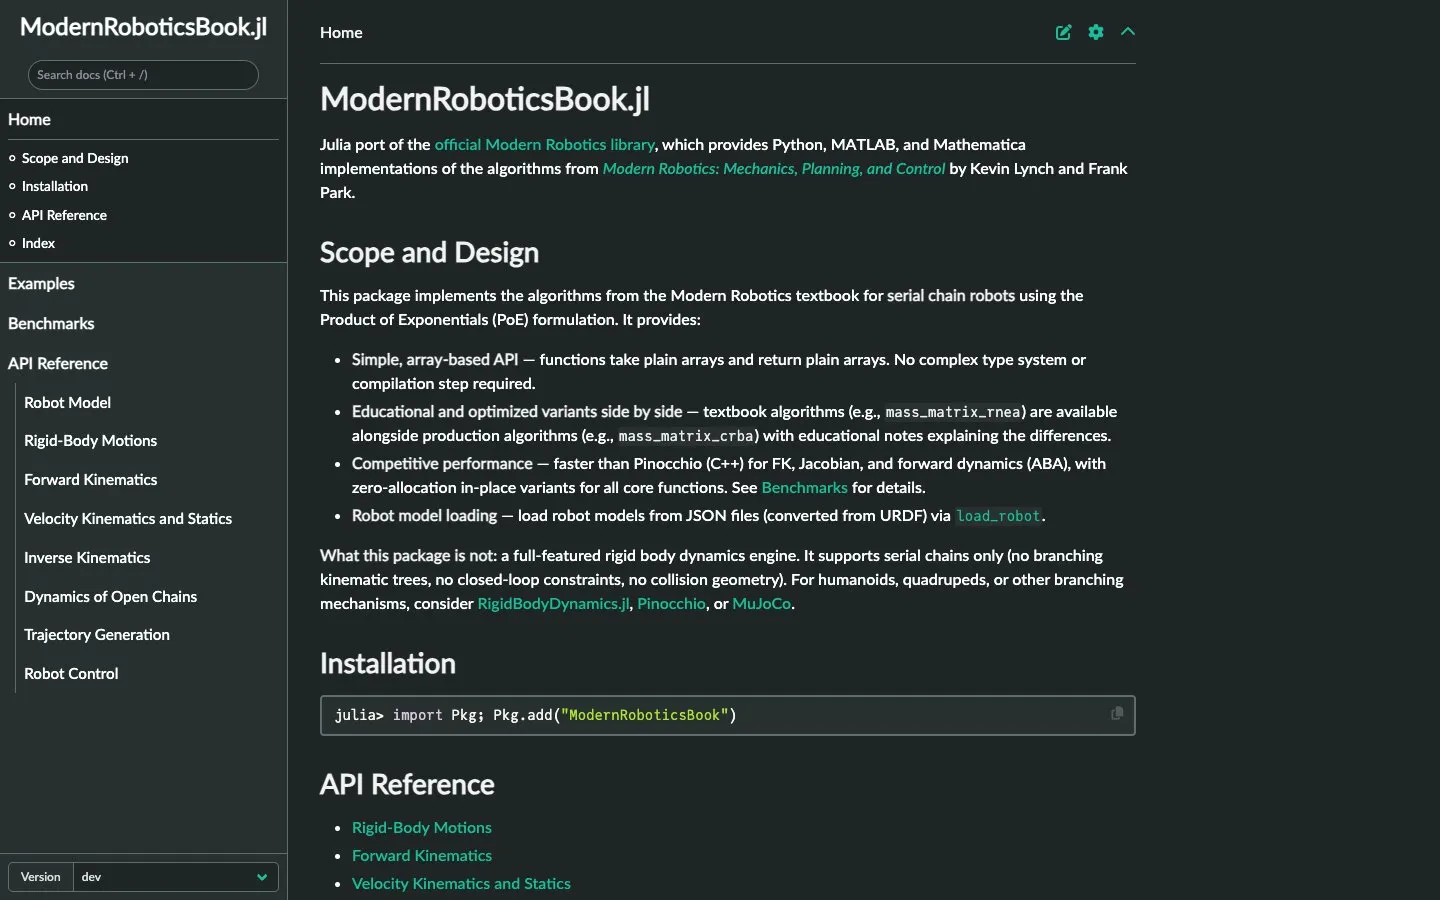
A Julia port of the official Modern Robotics library, which provides Python, MATLAB, and Mathematica implementations of the algorithms from Modern Robotics: Mechanics, Planning, and Control by Kevin Lynch and Frank Park.
The package provides functions for rigid-body motions, forward and inverse kinematics, velocity kinematics, dynamics, trajectory generation, and robot control. It is registered in the Julia General registry:
julia> import Pkg; Pkg.add("ModernRoboticsBook")Quick start
using ModernRoboticsBook

home_ee_pose = [-1  0  0  0
                 0  1  0  6
                 0  0 -1  2
                 0  0  0  1.0]
body_screw_axes = [0 0 -1 2 0   0
                   0 0  0 0 1   0
                   0 0  1 0 0 0.1]'
joint_positions = [π/2, 3, π]

T = forward_kinematics_body(home_ee_pose, body_screw_axes, joint_positions)