Robot Explorer
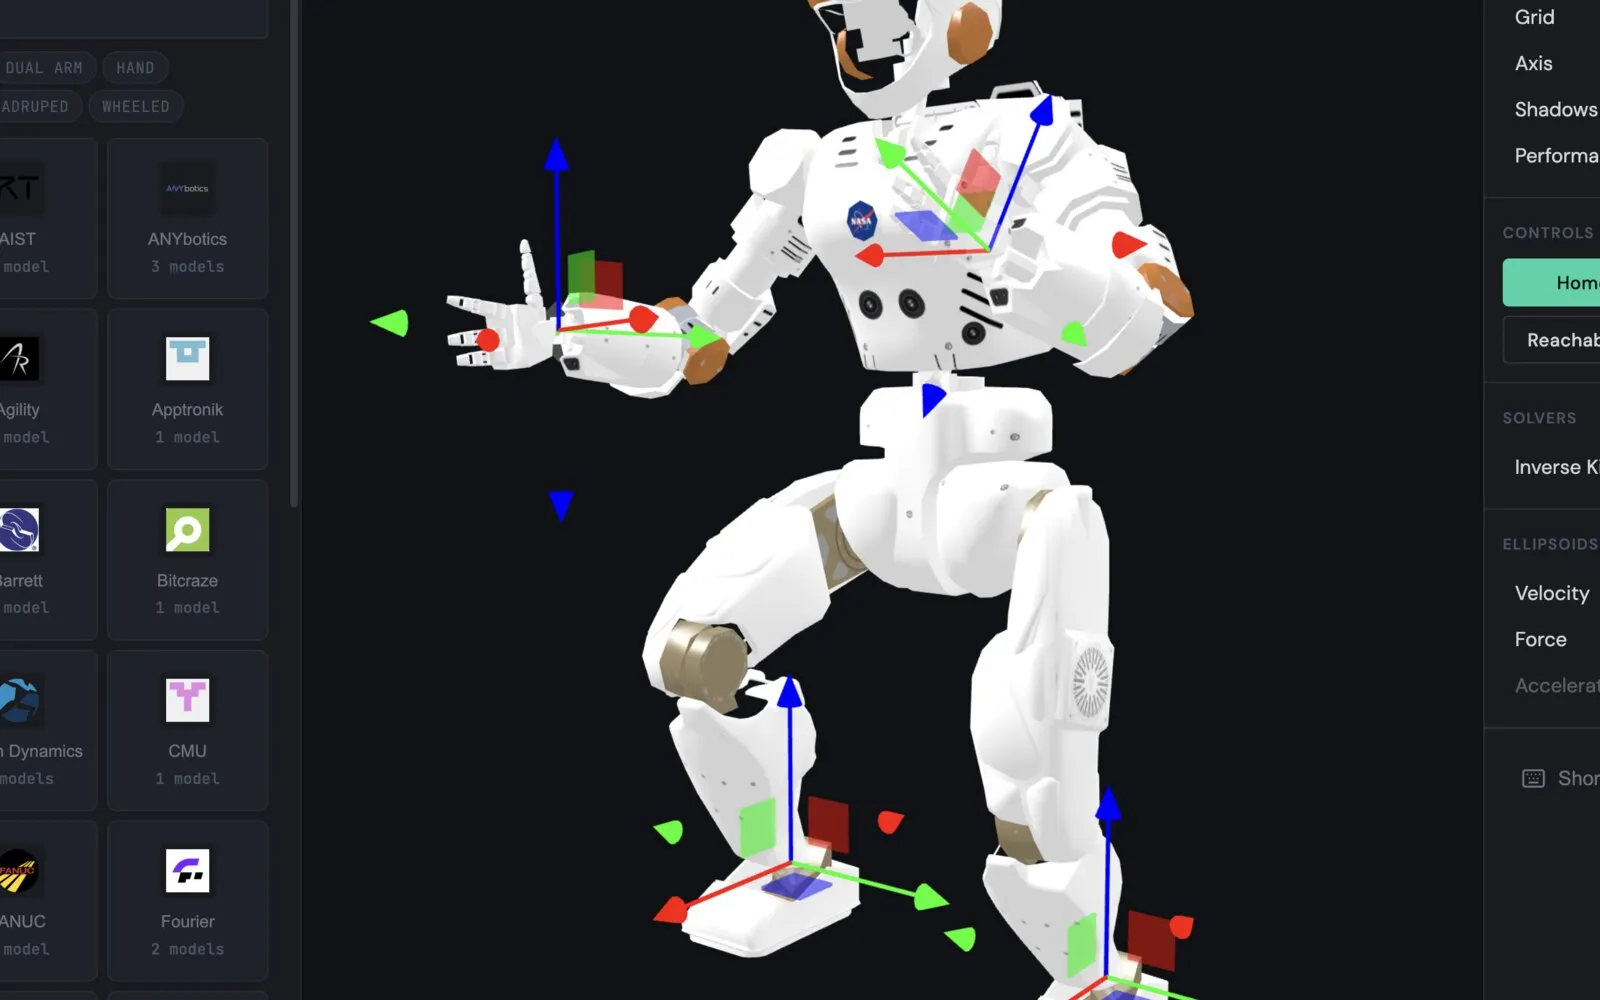
Browse 81+ robots from 35+ brands in the browser, with real-time inverse kinematics, manipulability ellipsoids, and force polytopes.
- Year
- 2017 – 2026
- Topics
- Robotics, Web tools, Education
- Stack
- TypeScript, Three.js, Vite
Open the live demo
Runs in your browser — nothing to install.
An interactive 3D web app for visualising and manipulating robot models with real-time forward and inverse kinematics. Robots are loaded as URDF models from a dedicated model repository.
Features
- Robot catalogue — 81+ URDF models from 35+ brands, in a two-level brand gallery with search and category filters.
- Forward and inverse kinematics — drag IK gizmos to pose end-effectors; revolute and prismatic joints, multi-tip whole-body IK, null-space limit avoidance, and joint-limit locking.
- Manipulability ellipsoids — velocity, acceleration, and force ellipsoids computed from the Jacobian and the joint-space inertia matrix.
- Force polytopes — the achievable end-effector force set from the URDF effort limits.
- Reachability clouds — sample random configurations to visualise the workspace.
- Motion keypoints — record, play back, and export convex hulls as STL.
- Educational panels — the maths behind IK and the capability visualisations, rendered with KaTeX.
- Three languages — English, Japanese, and Simplified Chinese; dark and light themes.
The project started in 2017 as a Three.js experiment and was rebuilt in TypeScript in 2026.