Rotary Inverted Pendulum
A £20 open-source Furuta pendulum that balances itself with a 689-parameter neural network running standalone on an Arduino Nano.
- Year
- 2024 – 2026
- Topics
- Robotics, Hardware, Simulation
- Stack
- Python, MuJoCo, Arduino, Astro
- Video views
- 31k
 Rotary Inverted Pendulum
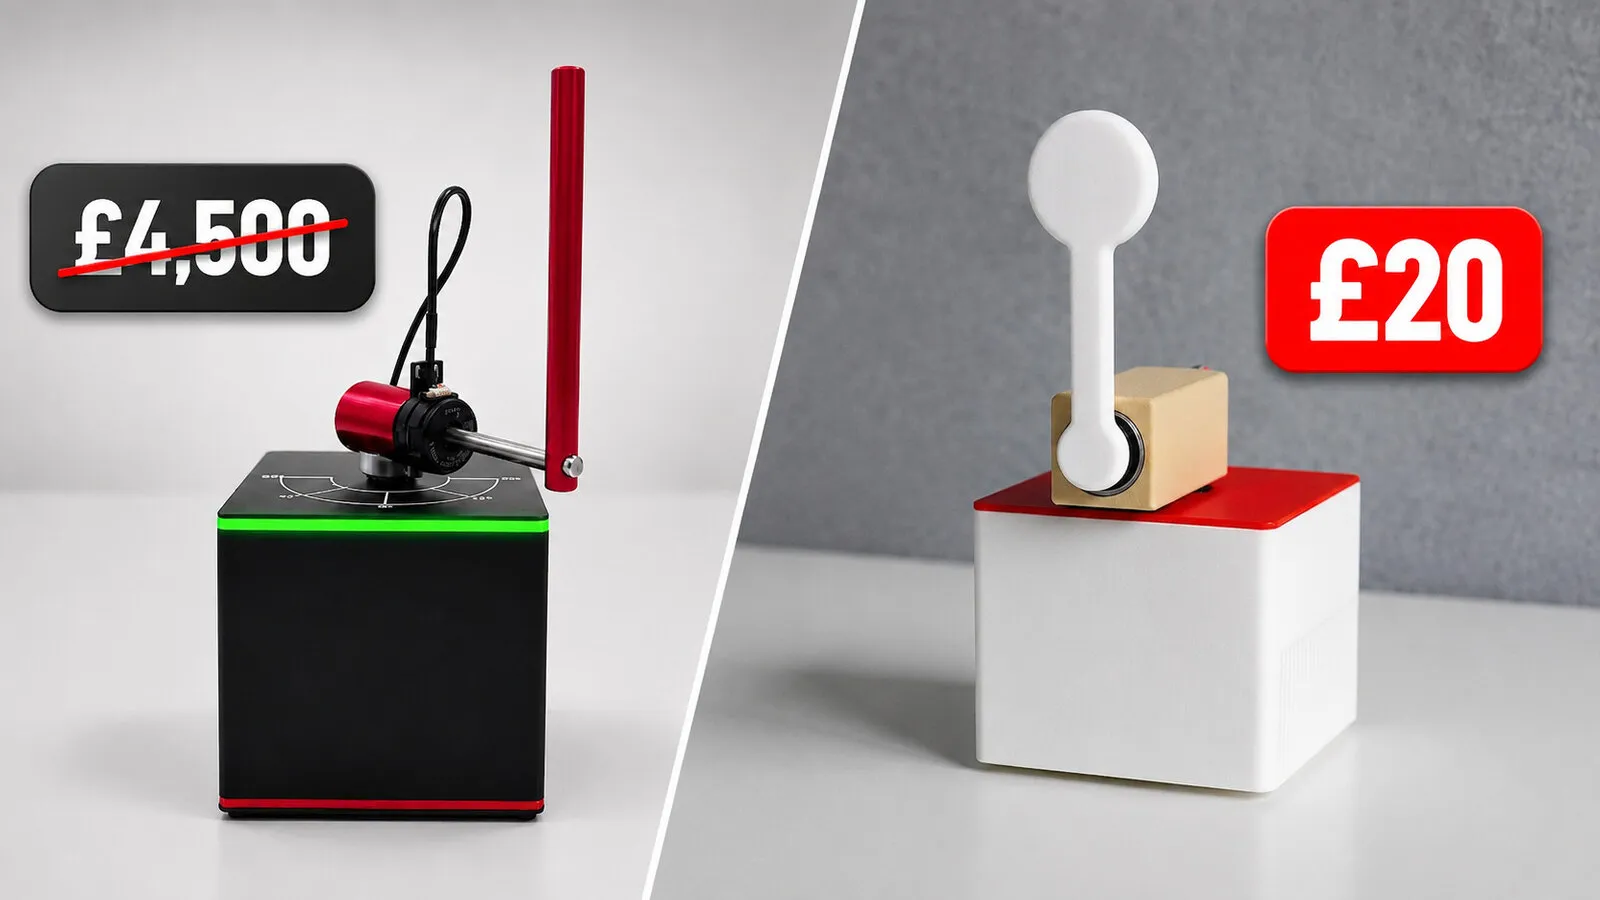
A DIY rotary inverted pendulum you can print, solder, and train at home for about £20 in parts — an open, hackable take on the rigs you would usually buy from a lab-equipment vendor (Quanser’s QUBE Servo 2 lists at around £4,500).
The pendulum balances itself with a reinforcement-learning policy trained in simulation, fine-tuned on the real hardware, and distilled into a 689-parameter network small enough to run standalone on an Arduino Nano.
The pipeline
The repository follows the pipeline end to end: measure the rig, train a policy, shrink it, flash it.
- Policy — a MuJoCo simulation environment, SAC training, system identification, a bridge to the real rig, distillation, and weight export.
- Firmware — the standalone RL controller, the low-level server used for fine-tuning, and the bring-up tests.
- Model — the URDF and the 3D-printable STLs it references, the single source of truth for the geometry.
- Documentation — an Astro Starlight site with a guided build and training path, plus an interactive 3D demo that runs the deployed network in your browser.
Where to start
- Build one — bill of materials → print → wire → first power-on.
- Train a policy — the end-to-end pipeline, step 0 through step 4.
- Understand the RL stack — the transition contract, domain randomisation, and transport delay.