Time-of-Flight 3D Scanner
Turn a £5 VL53L5CX multi-zone ToF sensor and an IMU into a real-time 3D point-cloud viewer and room mapper.
- Year
- 2026
- Topics
- Hardware, Robotics
- Stack
- Python, ESP32, viser
- Video views
- 389k
 Time-of-Flight 3D Scanner
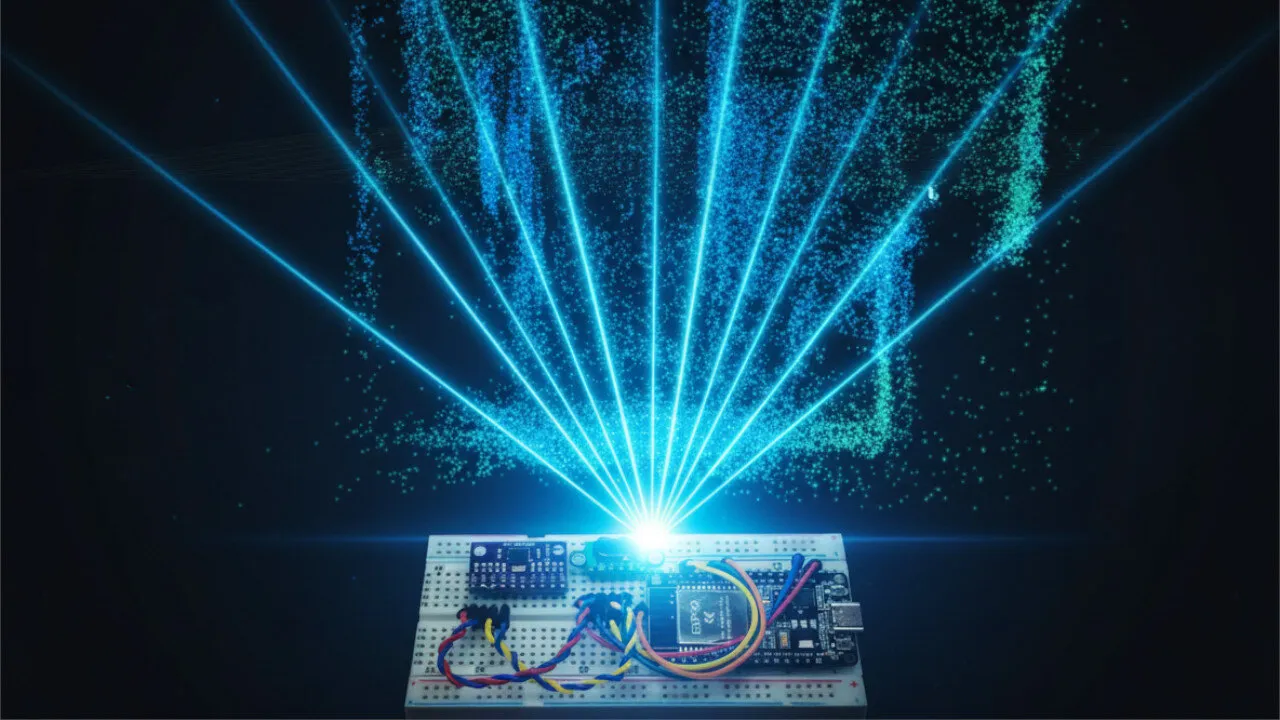
A real-time 3D point-cloud viewer for the VL53L5CX multi-zone time-of-flight sensor, with BNO085 IMU orientation tracking for basic room mapping. The whole setup costs about £24 in parts from AliExpress: an ESP32, the ToF sensor, and the IMU, all sharing one I²C bus.
Features
- 64-zone 3D visualisation — the sensor’s 8×8 measurement grid drawn as rays in 3D space.
- Real-time IMU tracking — the BNO085 orientation rotates the virtual view to match the physical sensor.
- Temporal filtering — an exponential moving average smooths noisy measurements.
- Plane fitting — least squares and RANSAC for surface detection.
- Mapping mode — accumulate points over time to build a 3D map of the room.
How it works
The ESP32 streams JSON over serial at 115200 baud: 64 perpendicular distances, 64 status flags, and the IMU quaternion. A Python viewer built on viser turns that into rays and points in the browser.
The sensor runs at 8×8 resolution and 15 Hz, over a range of 20 mm to 4 m with a 65° diagonal field of view.