RoLoMa
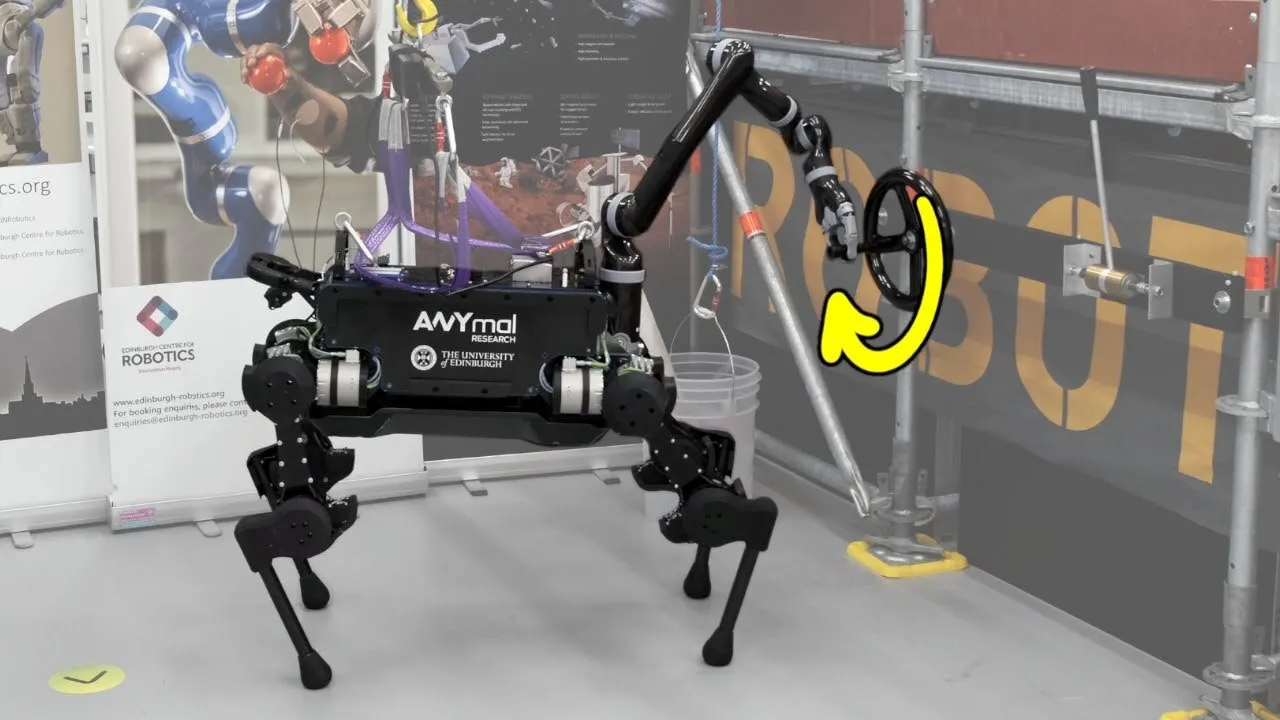
Robust loco-manipulation for quadrupeds with arms — trajectories that resist stronger disturbances, from any direction, while pulling levers and turning wheels.
- Year
- 2023
- Topics
- Robotics, Optimisation
- Stack
- Julia, Trajectory optimisation, ANYmal
 RoLoMa
Real-world deployment demands robustness to model mismatch, sensor noise, and communication delays. Controllers can react to those at run time — but online execution can only ever be as robust as the motion plan allows. RoLoMa makes robustness a first-class objective at the planning stage.
We derive a metric from first principles that represents robustness against external disturbances — the smallest unrejectable force — and use it inside our trajectory optimisation framework to solve complex loco-manipulation tasks on an ANYmal quadruped with a robotic arm.
Results
Trajectories generated with this approach resist a greater range of forces, originating from any direction. They solve the tasks as effectively as before, with the added benefit of counteracting stronger disturbances in worst-case scenarios — demonstrated on hardware turning a hand wheel, pulling a lever, and lifting increasingly heavy loads.
Published in Autonomous Robots (2023). The paper page has the full abstract and all the supplementary videos.