TORA.jl
Trajectory Optimisation for Robot Arms — describe a task at a high level and get a full, dynamically consistent trajectory back.
- Year
- 2020 – 2023
- Topics
- Robotics, Optimisation
- Stack
- Julia, Ipopt, Knitro, MeshCat
 TORA.jl
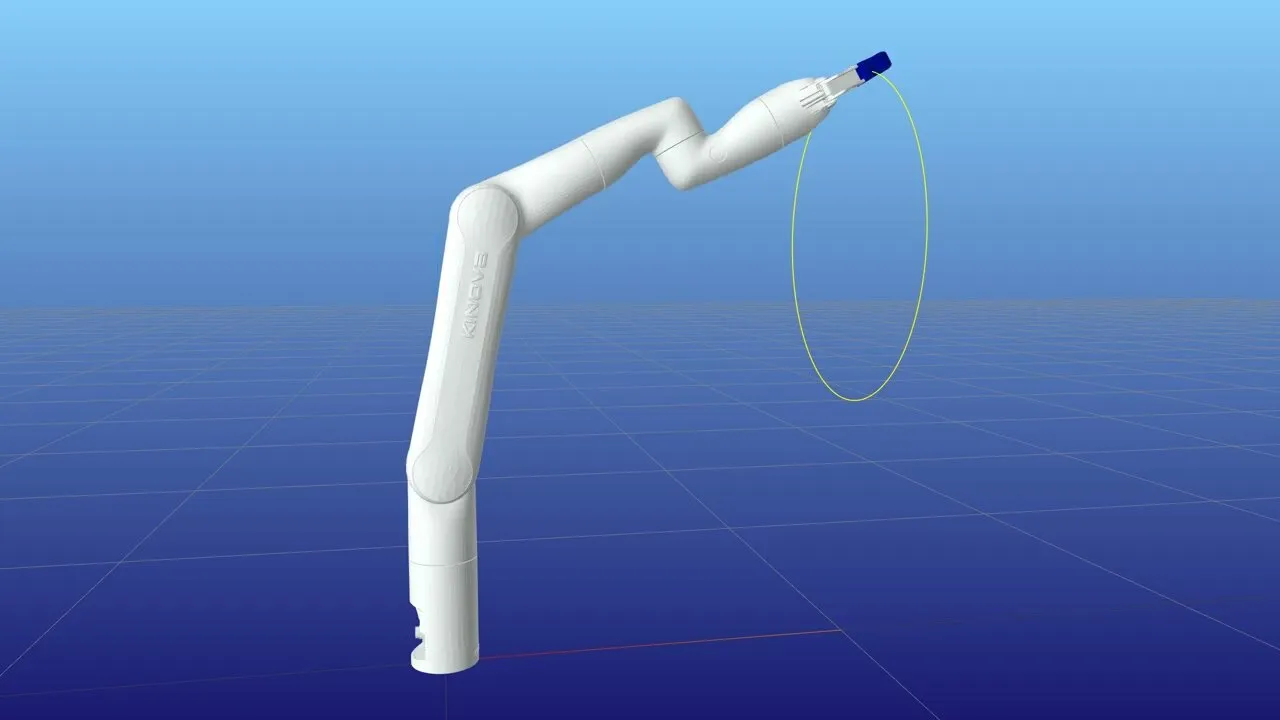
TORA stands for Trajectory Optimization for Robot Arms. You define tasks for robot manipulators with simple high-level descriptions, and TORA.jl does the heavy lifting: it converts them into numerical optimisation problems and hands those to state-of-the-art solvers.
The result is a full trajectory — joint positions, velocities, and torques — that accounts for the whole-body dynamics of the robot, ready to be commanded in simulation or on real hardware.
Highlights
- A simple interface for constrained motion-planning problems.
- The optimal control problem formulated with direct transcription.
- NLPs solved with Ipopt and Knitro.
- Full system dynamics enforced with either forward or inverse dynamics (RigidBodyDynamics.jl).
- Automatic differentiation of sparse Jacobians, with automatic sparsity detection.
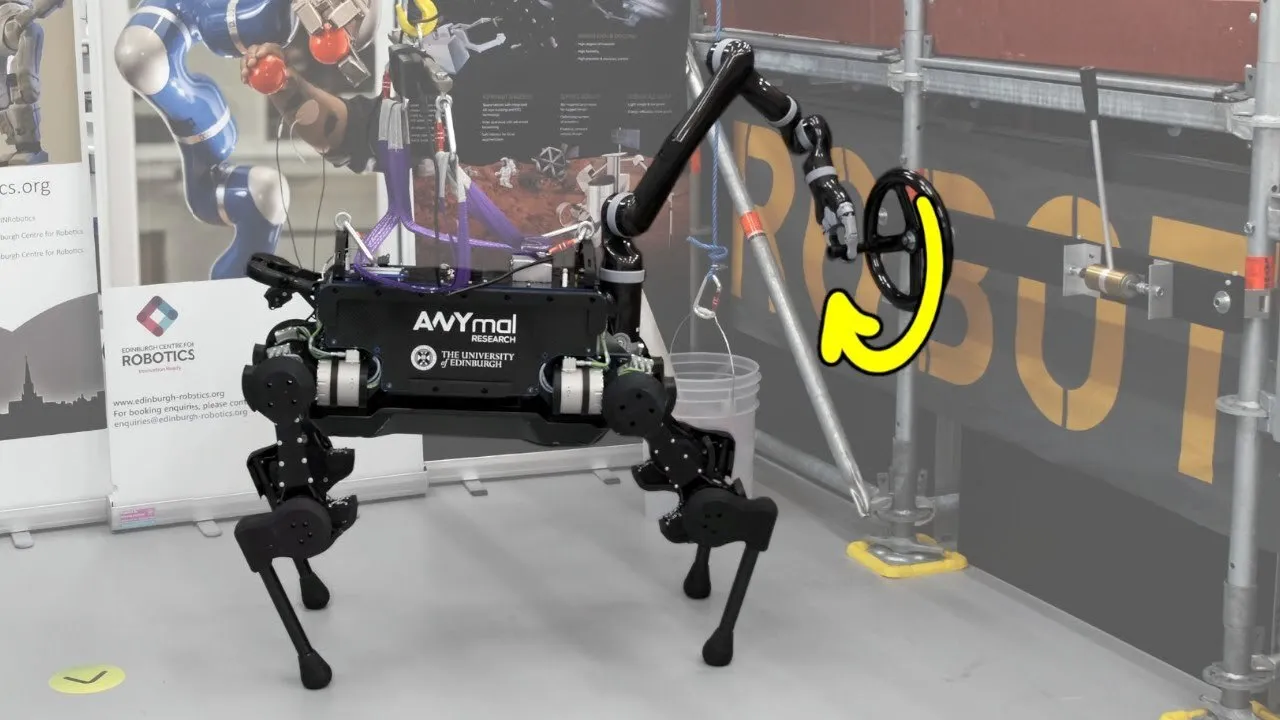
The package lives in the JuliaRobotics organisation. The video above is my JuliaCon 2023 talk at MIT, Using Julia to Optimise Trajectories for Robots with Legs, which is linked from the TORA.jl README.