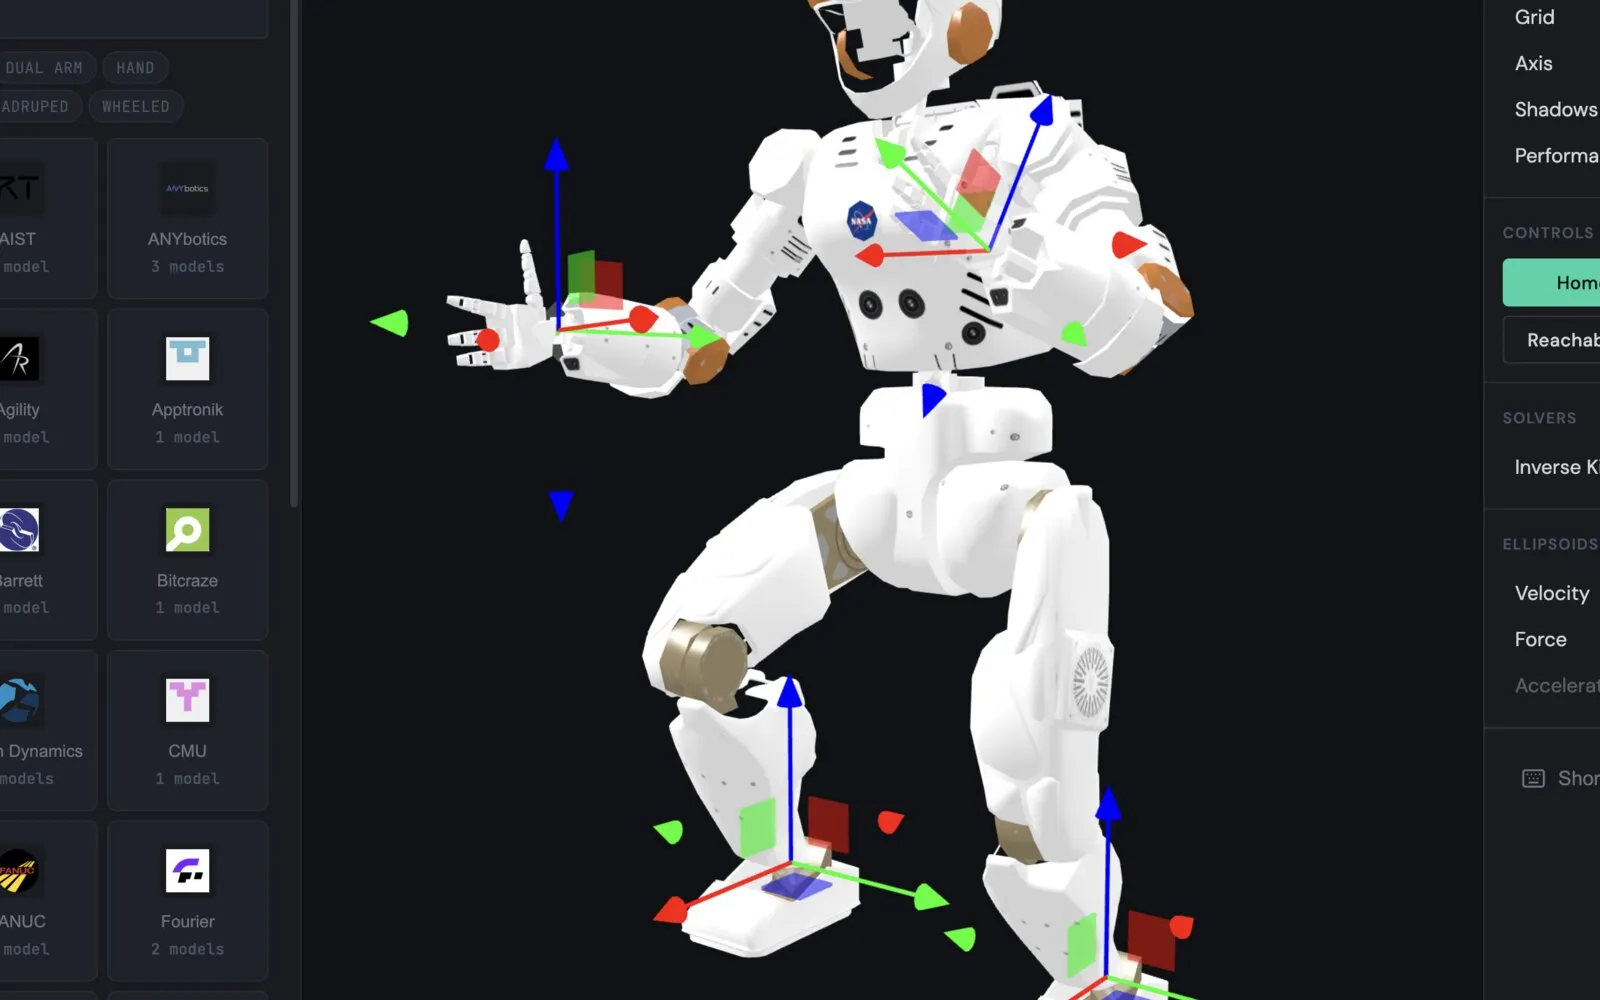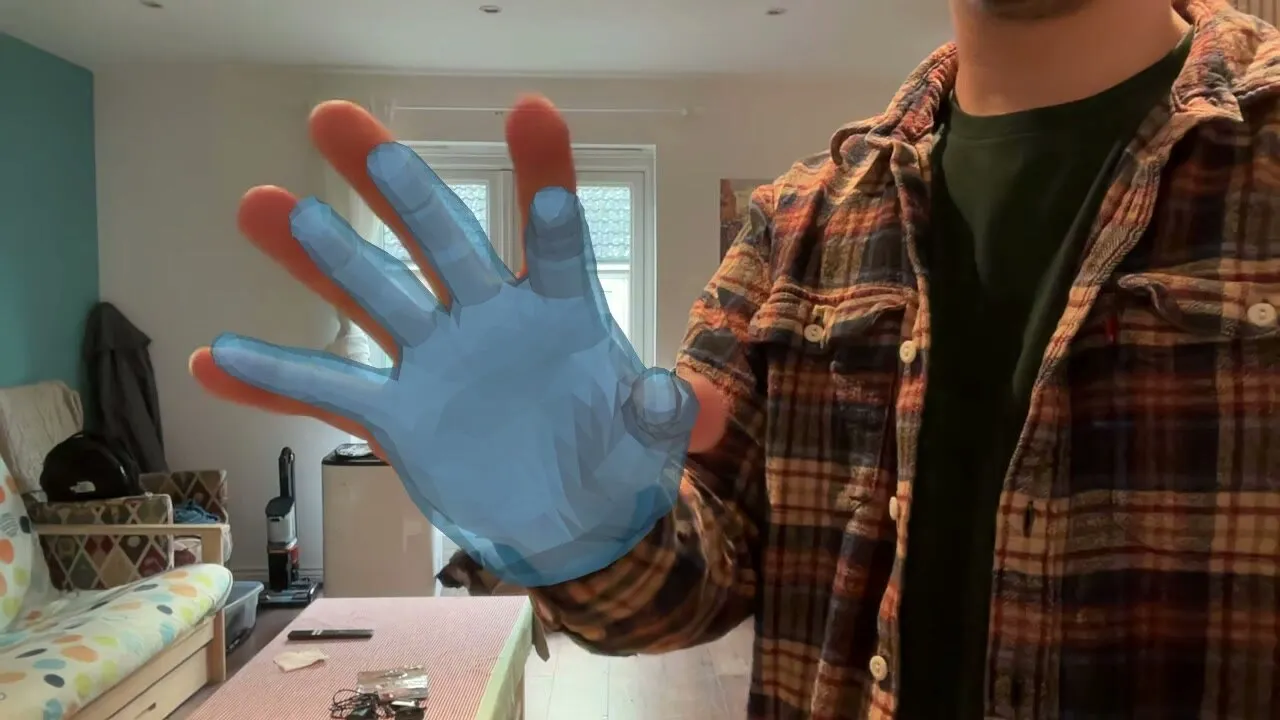
Experiments in monocular hand tracking, aimed at interactively teleoperating a 3D hand in viser and, eventually, retargeting to a robot hand. Robotics-focused — joint positions over photorealistic meshes — and running on an Apple Silicon MacBook Air.
The live browser demo runs entirely on your own webcam (MediaPipe + Three.js), with nothing to install.
Two trackers for two jobs
Both sit behind one swappable frame → tracker → 21 keypoints → viser pipeline.
| Live teleop | Offline policy data | |
|---|---|---|
| Tracker | MediaPipe Hands | WiLoR (via wilor-mini) |
| Speed (M2 Air) | ~40 fps | ~4 fps |
| Output | 21 keypoints | full MANO (rotations + mesh) |
| Why | a human closes the loop, so latency wins | no human in the loop, so accuracy and occlusion robustness win |
Placing the hand in 3D
Articulation comes from MediaPipe’s metric world landmarks. Global placement comes from the image landmarks, back-projected with the camera intrinsics: depth is estimated from the known metric hand size against its apparent size in pixels (Z = fx · size / pixels).